맵 작성
R2026b함수
도움말 항목
- Occupancy Grids
Details of occupancy grid functionality and map structure.
- Fuse Multiple Lidar Sensors Using Map Layers
Occupancy maps offer a simple yet robust way of representing an environment for robotic applications by mapping the continuous world-space to a discrete data structure.
- Build Occupancy Map from Depth Images Using Visual Odometry and Optimized Pose Graph
This example shows how to reduce the drift in the estimated trajectory (location and orientation) of a monocular camera using 3-D pose graph optimization.
추천 예제
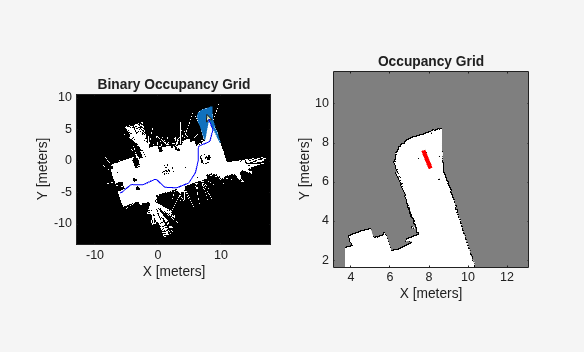
Create Egocentric Occupancy Maps Using Range Sensors
Occupancy Maps offer a simple yet robust way of representing an environment for robotic applications by mapping the continuous world-space to a discrete data structure. Individual grid cells can contain binary or probabilistic information, where 0 indicates free-space, and 1 indicates occupied space. You can build up this information over time using sensor measurements and efficiently store them in the map. This information is also useful for more advanced workflows, such as collision detection and path planning.
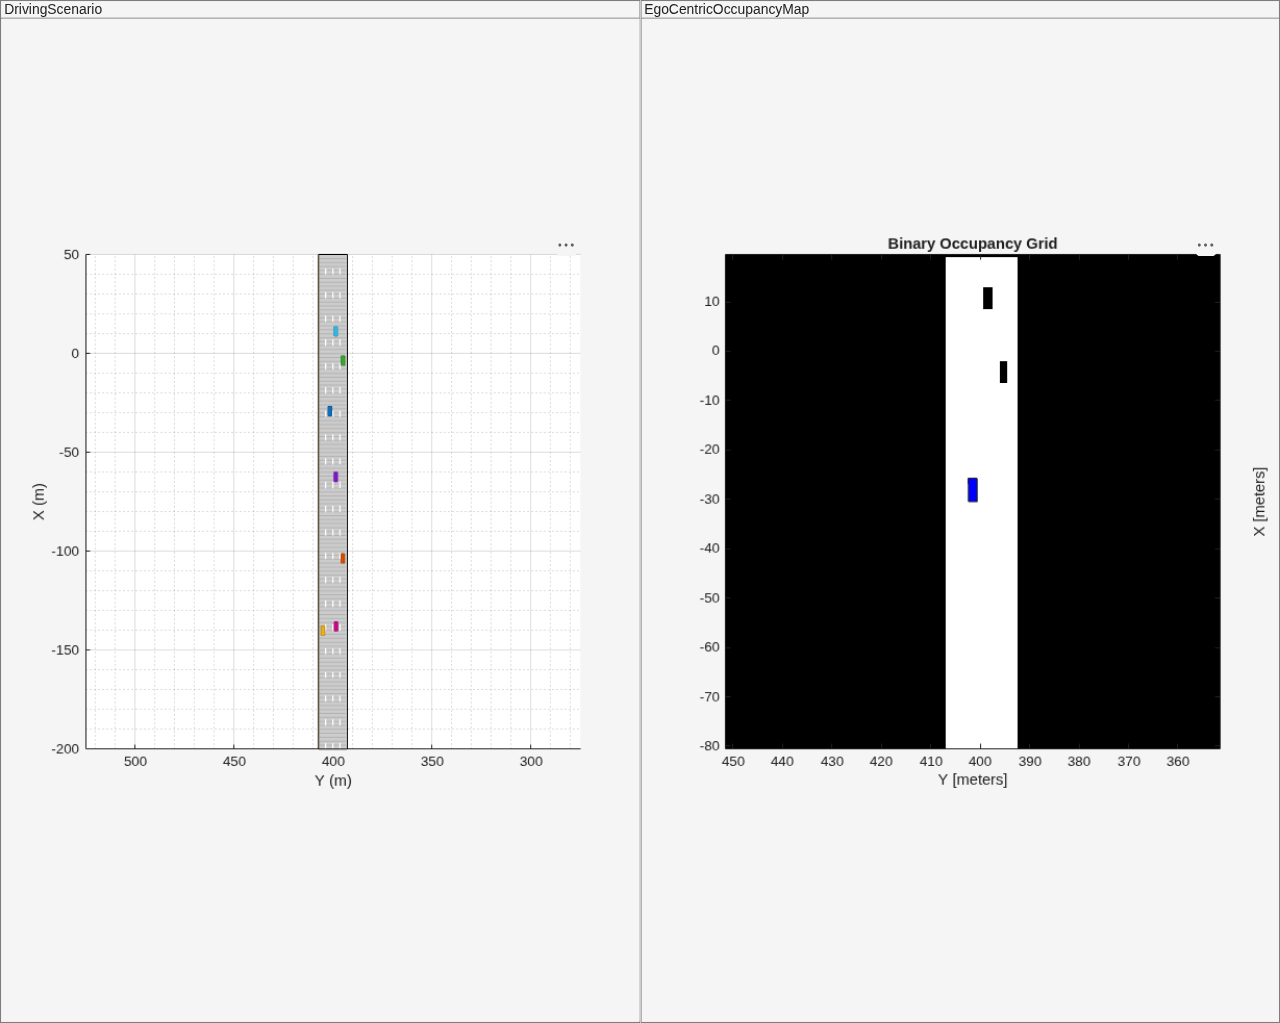
Create Egocentric Occupancy Map from Driving Scenario Designer
Create an egocentric occupancy map from the Driving Scenario Designer app. This example uses obstacle information from the vision detection generator to update the egocentric occupancy map.
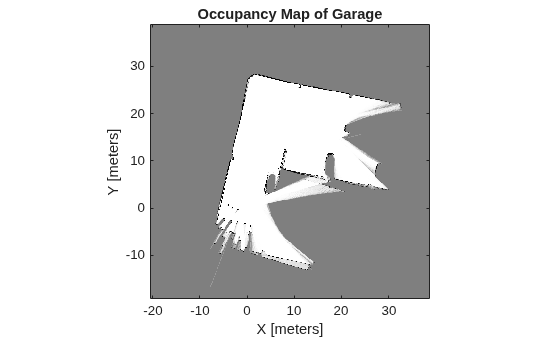
라이다 스캔과 자세를 이용해 점유 맵 작성하기
buildMap 함수는 라이다 스캔 측정값 및 연관된 자세를 사용하여 점유 그리드를 lidarScan 객체 및 연관된 [x y theta] 자세로 구축하고 occupancyMap을 작성합니다.

