SLAM
R2026bSLAM(동시적 위치추정 및 지도작성)은 맵 작성 및 위치추정 알고리즘 항목을 모두 사용하여 맵을 작성하는 동시에 해당 맵 내에서 이동체의 위치를 추정합니다. lidarSLAM을 사용하면 라이다 스캔과 오도메트리 자세 추정값을 처리하는 사용자 자신의 SLAM 알고리즘을 조정하여 맵을 반복적으로 작성할 수 있습니다. buildMap을 사용하면 기록되고 필터링된 데이터를 취하고 SLAM을 사용해 맵을 만들 수 있습니다. SLAM 맵 작성기 앱을 사용하면 관련 자세를 수동으로 수정하고 스캔을 정렬하여 맵의 정확도를 개선할 수 있습니다.
SLAM이 무엇인지, 그리고 다른 MATLAB® 툴박스의 SLAM 툴에 대해 자세히 알아보려면 SLAM이란?을 참조하십시오.
앱
| SLAM 맵 작성기 | 라이다 기반 SLAM을 사용하여 2차원 그리드 맵 작성 |
함수
monovslam | Visual simultaneous localization and mapping (vSLAM) and visual-inertial sensor fusion with monocular camera (R2025a 이후) |
rgbdvslam | Feature-based visual simultaneous localization and mapping (vSLAM) and visual-inertial sensor fusion with RGB-D camera (R2025a 이후) |
stereovslam | Feature-based visual simultaneous localization and mapping (vSLAM) and visual-inertial sensor fusion with stereo camera (R2025a 이후) |
ekfSLAM | Perform simultaneous localization and mapping using extended Kalman filter |
factorGraph | Graph-based framework for multisensor state estimation (R2022a 이후) |
importFactorGraph | Import factor graph from g2o log file (R2022a 이후) |
factorIMU | Convert IMU readings to factor (R2022a 이후) |
factorGPS | Factor for GPS measurement (R2022a 이후) |
factorTwoPoseSE2 | Factor relating two SE(2) poses (R2022a 이후) |
factorTwoPoseSE3 | Relative pose factor connecting two SE(3) poses (R2022a 이후) |
factorTwoPoseSIM3 | Factor relating two SIM(3) poses (R2025a 이후) |
factorPoseSE2AndPointXY | Factor relating SE(2) position and 2-D point (R2022b 이후) |
factorPoseSE3AndPointXYZ | Factor relating SE(3) position and 3-D point (R2022b 이후) |
factorIMUBiasPrior | Prior factor for IMU bias (R2022a 이후) |
factorVelocity3Prior | Prior factor for 3-D velocity (R2022a 이후) |
factorPoseSE3Prior | Full-state prior factor for SE(3) pose (R2022a 이후) |
factorTransformSE3Prior | Full-state prior factor for SE(3) transform (R2026a 이후) |
factorCameraSE3AndPointXYZ | Factor relating SE(3) camera pose, 3-D landmark point, and optional sensor transform (R2023a 이후) |
estimateGravityRotation | Estimate gravity rotation using factor graph optimization (R2023a 이후) |
estimateGravityRotationAndPoseScale | Estimate gravity rotation and pose scale using factor graph optimization (R2023a 이후) |
estimateCameraIMUTransform | Estimate transformation from camera to IMU sensor using calibration data (R2024a 이후) |
poseGraph | 2차원 자세 그래프 만들기 |
poseGraph3D | 3차원 자세 그래프 만들기 |
poseGraphSolverOptions | Solver options for pose graph optimization |
optimizePoseGraph | Optimize nodes in pose graph |
trimLoopClosures | Optimize pose graph and remove bad loop closures |
poseplot | 3차원 자세 플롯 |
도움말 항목
- Choose SLAM Workflow Based on Sensor Data
Choose the right simultaneous localization and mapping (SLAM) workflow and find topics, examples, and supported features.
- Factor Graph for SLAM
Learn about factor graph and how it use it for SLAM applications.
추천 예제
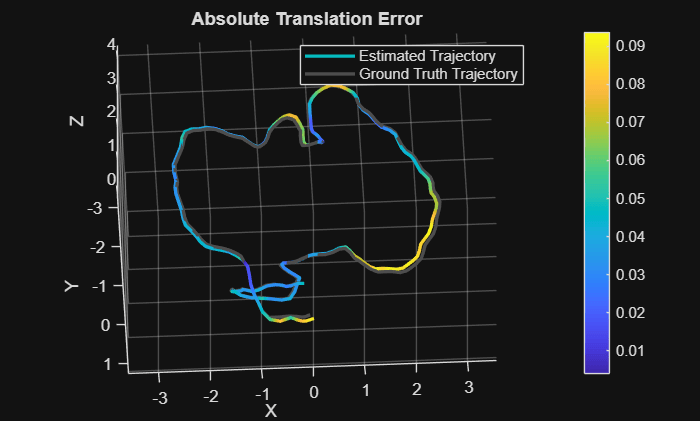
Performant and Deployable Monocular Visual SLAM
Visual simultaneous localization and mapping (vSLAM) refers to the process of calculating the position and orientation of a camera with respect to its surroundings while simultaneously mapping the environment. Applications for vSLAM include augmented reality, robotics, and autonomous driving. In this example, the algorithm uses only visual inputs from the camera.
- R2024a 이후
- 라이브 스크립트 열기
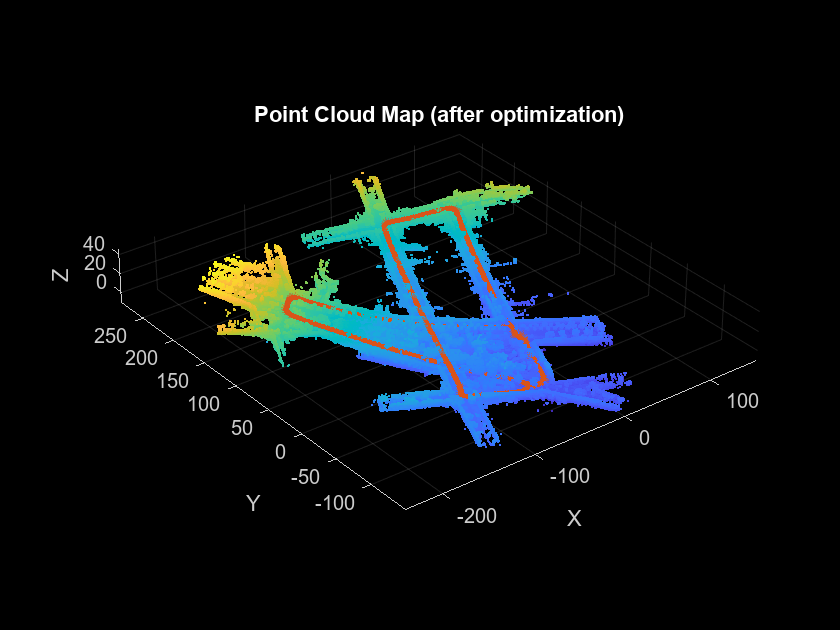
Build a Map from Lidar Data Using SLAM
Process 3-D lidar data from a sensor on a vehicle to progressively build a map and estimate the trajectory using SLAM.
- R2024a 이후
- 라이브 스크립트 열기
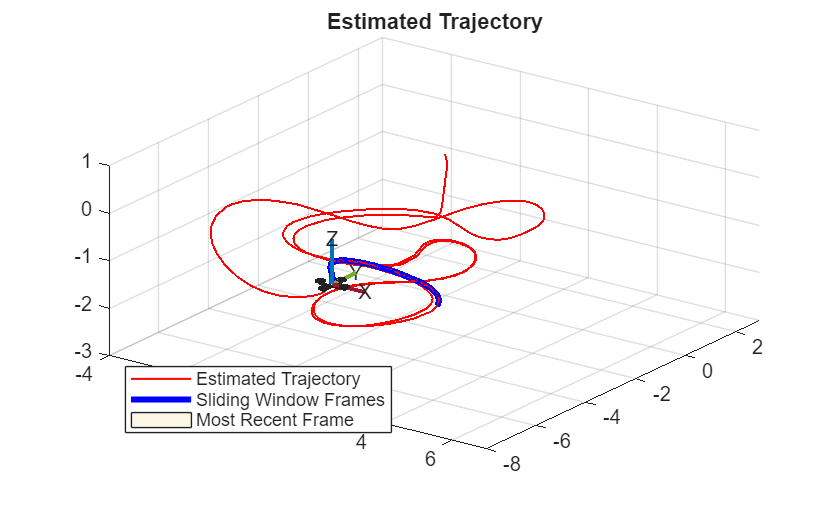
Monocular Visual-Inertial Odometry (VIO) Using Factor Graph
Implement monocular visual-inertial odometry to localize a UAV using camera and IMU data, optimized by a factor graph.
- R2023b 이후
- 라이브 스크립트 열기
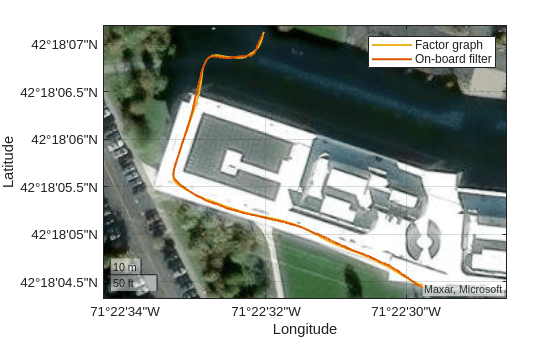
Factor Graph-Based Pedestrian Localization with IMU and GPS Sensors
Estimate the position of a pedestrian using logged sensor data from an inertial measurement unit (IMU) and Global Positioning System (GPS) receiver and a factor graph.
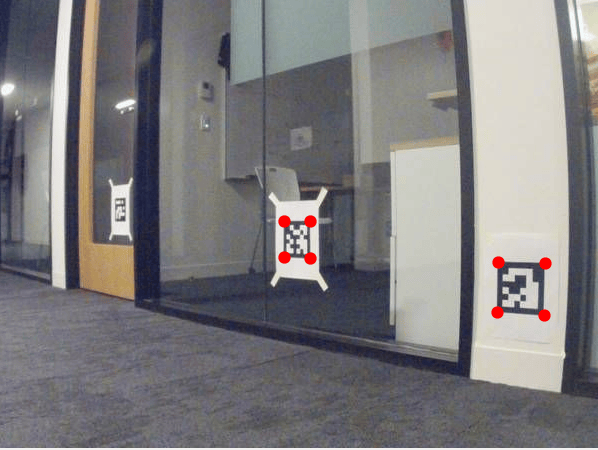
Landmark SLAM Using AprilTag Markers
Combine robot odometry data and AprilTag markers to implement SLAM with a factor graph and pose graph, and compare the results.
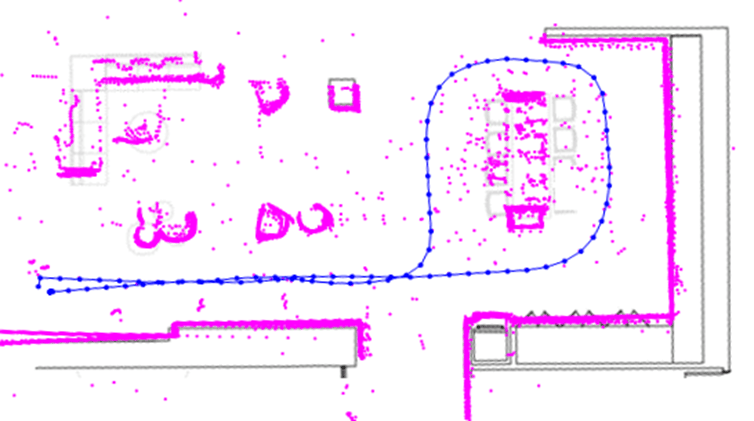
Map Indoor Area Using Lidar SLAM and Factor Graph
Implement offline lidar SLAM on collected lidar scans to map an indoor area using a factor graph and lidar scan map.
Build and Deploy Visual SLAM Algorithm with ROS in MATLAB
Implement a monocular visual SLAM algorithm to estimate camera poses and deploy generated C++ code using ROS.
Simulate RGB-D Visual SLAM System with Cosimulation in Gazebo and Simulink
Use RGB and depth images from a robot to simulate a RGB-D visual SLAM system in Simulink.
- R2024b 이후
- 라이브 스크립트 열기
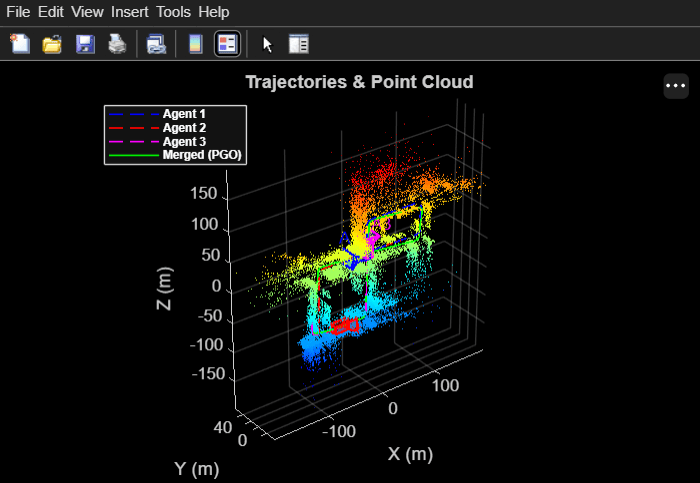
Map Large Environments Using Multi-Agent Collaborative SLAM
Map a large environment using multiple stereo-camera agents that independently run visual SLAM, detect shared locations via visual place recognition, and merge their maps through pose graph optimization.
(Computer Vision Toolbox)
- R2026b 이후
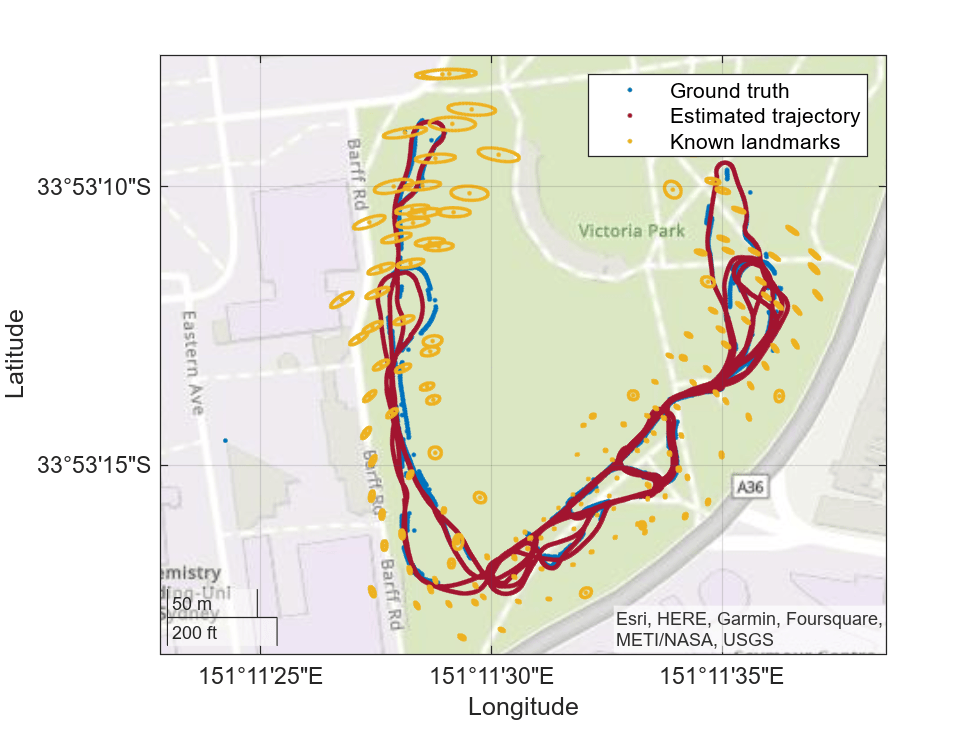
EKF-Based Landmark SLAM
Implement landmark SLAM using the Extended Kalman Filter algorithm to track the path of a vehicle and map the surroundings.
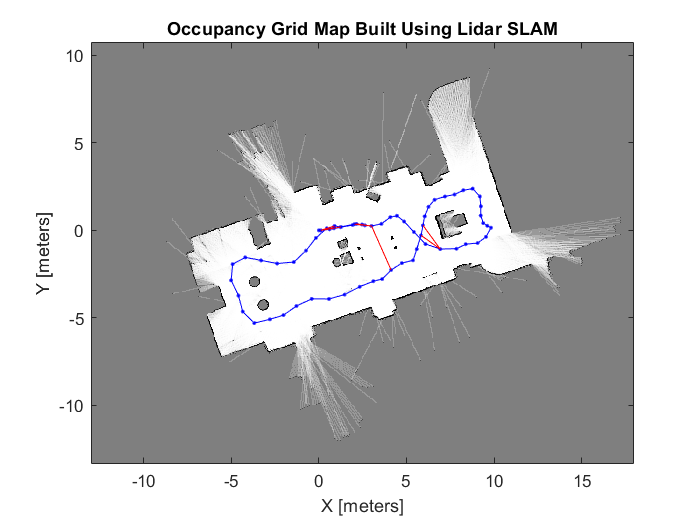
라이다 스캔으로 SLAM(동시적 위치추정 및 지도작성) 구현하기
자세 그래프와 일련의 라이다 스캔 컬렉션을 사용하여 오프라인 SLAM을 구현하고 환경 맵을 작성합니다.
MATLAB Command
You clicked a link that corresponds to this MATLAB command:
Run the command by entering it in the MATLAB Command Window. Web browsers do not support MATLAB commands.
웹사이트 선택
번역된 콘텐츠를 보고 지역별 이벤트와 혜택을 살펴보려면 웹사이트를 선택하십시오. 현재 계신 지역에 따라 다음 웹사이트를 권장합니다:
또한 다음 목록에서 웹사이트를 선택하실 수도 있습니다.
사이트 성능 최적화 방법
최고의 사이트 성능을 위해 중국 사이트(중국어 또는 영어)를 선택하십시오. 현재 계신 지역에서는 다른 국가의 MathWorks 사이트 방문이 최적화되지 않았습니다.
미주
- América Latina (Español)
- Canada (English)
- United States (English)
유럽
- Belgium (English)
- Denmark (English)
- Deutschland (Deutsch)
- España (Español)
- Finland (English)
- France (Français)
- Ireland (English)
- Italia (Italiano)
- Luxembourg (English)
- Netherlands (English)
- Norway (English)
- Österreich (Deutsch)
- Portugal (English)
- Sweden (English)
- Switzerland
- United Kingdom (English)


