이 페이지의 내용은 이전 릴리스에 관한 것입니다. 해당 영문 페이지는 최신 릴리스에서 제거되었습니다.
포인트 클라우드 처리
R2026a포인트 클라우드는 3차원 공간에 속한 데이터 점들의 집합입니다. 이러한 점들이 합쳐져 3차원 형상이나 객체를 표현합니다. 데이터 집합의 각 점은 x, y, z 기하 좌표로 표현됩니다. 포인트 클라우드는 많은 수의 개개의 공간적 측정값을 설명 가능한 객체로 표현할 수 있는 데이터셋으로 조합하는 수단을 제공합니다. 포인트 클라우드 처리는 로봇 주행과 인식, 깊이 추정, 스테레오 비전, 시각적 정합, 첨단 운전자 보조 시스템(ADAS)에 사용됩니다. Computer Vision Toolbox™ 알고리즘은 다운샘플링, 잡음 제거 및 포인트 클라우드 변환을 위한 포인트 클라우드 처리 기능을 제공합니다. 또한, 포인트 클라우드 정합을 수행하고, 기하학적 형상을 3차원 포인트 클라우드에 피팅하고, 포인트 클라우드를 읽기, 쓰기, 저장, 표시, 비교하는 기능을 제공합니다. 여러 포인트 클라우드를 결합하여 하나의 3차원 장면을 복원하거나, 정합된 포인트 클라우드로 맵을 작성하고, 루프 폐쇄를 검출하고, 맵을 드리프트 보정에 최적화하고, 사전 작성된 맵에서 위치추정을 수행할 수 있습니다. 자세한 내용은 항목을 참조하십시오.
둘 이상의 포인트 클라우드를 하나의 좌표계에 정렬하는 과정인 포인트 클라우드 정합을 수행하려면, 일반적으로 한 클라우드를 기준 클라우드나 고정 포인트 클라우드로 지정한 다음, 다른 포인트 클라우드인 이동 포인트 클라우드를 이 클라우드에 맞춰 정렬합니다. 포인트 클라우드의 절대 자세는 흔히 세계 좌표계라고 하는 기준 좌표계를 기준으로 한 전역 위치와 방향을 나타냅니다. Computer Vision Toolbox는 이동 포인트 클라우드를 고정 포인트 클라우드에 정합하는 다양한 정합 기법을 제공합니다. 이러한 기법에는 ICP(Iterative Closest Point), NDT(Normal-Distributions Transform), 위상 상관, CPD(Coherent Point Drift) 등이 있습니다. 또한 라이다 정합 분석기 (Point Cloud Toolbox) 앱에서는 대화형 방식으로 다양한 정합 기법과 조정 파라미터, 전처리 단계를 사용하여 정합을 수행하고 그 결과를 비교할 수 있습니다.
함수
블록
 | Point Cloud Viewer | Visualize streaming point cloud data sequence (R2023a 이후) |
도움말 항목
- 포인트 클라우드 뷰어 선택하기
시각화 함수를 비교합니다.
- Choose SLAM Workflow Based on Sensor Data
Choose the right simultaneous localization and mapping (SLAM) workflow and find topics, examples, and supported features.
- Getting Started with Point Clouds Using Deep Learning
Understand how to use point clouds for deep learning.
- Getting Started with Point Clouds Using Deep Learning
Understand how to use point clouds for deep learning.
- Choose Function to Visualize Detected Objects
Compare visualization functions.
- 레이블 지정, 분할, 검출 (Point Cloud Toolbox)
딥러닝과 기하 알고리즘을 사용하여 포인트 클라우드 데이터 내 객체에 레이블을 지정하고, 객체를 분할, 검출 및 분류
추천 예제
Build a Map from Lidar Data Using SLAM
Process lidar data to build a map and estimate a vehicle trajectory using simultaneous localization and mapping.
Build a Map from Lidar Data Using SLAM on GPU
Perform 3-D simultaneous localization and mapping (SLAM) on an NVIDIA® GPU.
Build a Map from Lidar Data
Process 3-D lidar sensor data to progressively build a map, with assistance from inertial measurement unit (IMU) readings.
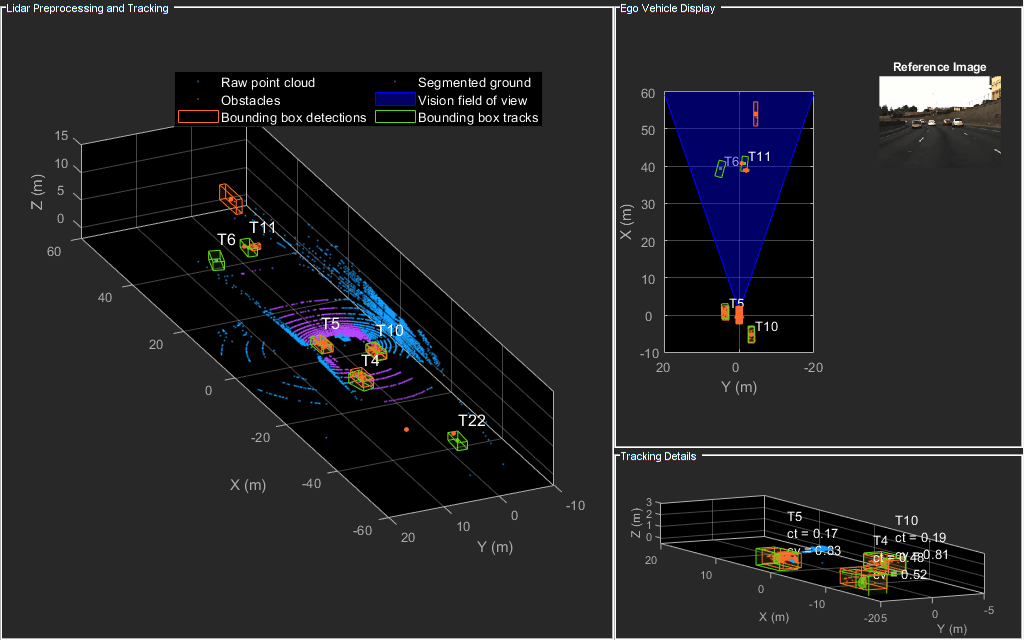
Detect and Track Vehicles Using Lidar Data
Track vehicles using measurements from a lidar sensor mounted on top of an ego vehicle.
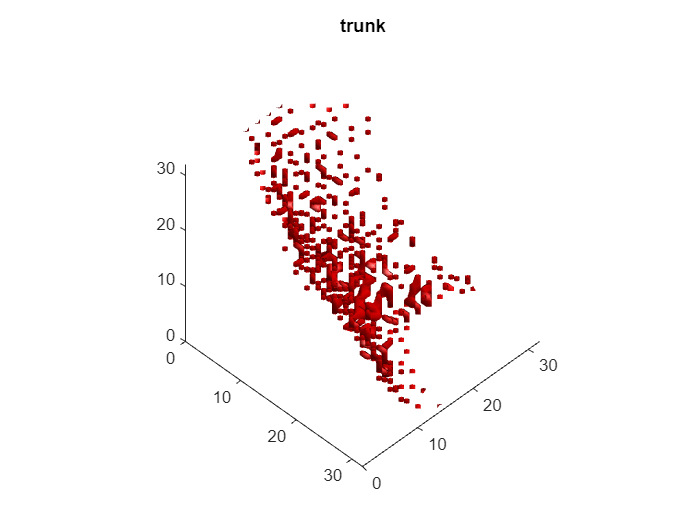
Train Classification Network to Classify Object in 3-D Point Cloud
Train a classification network to classify objects in a 3-D point cloud.
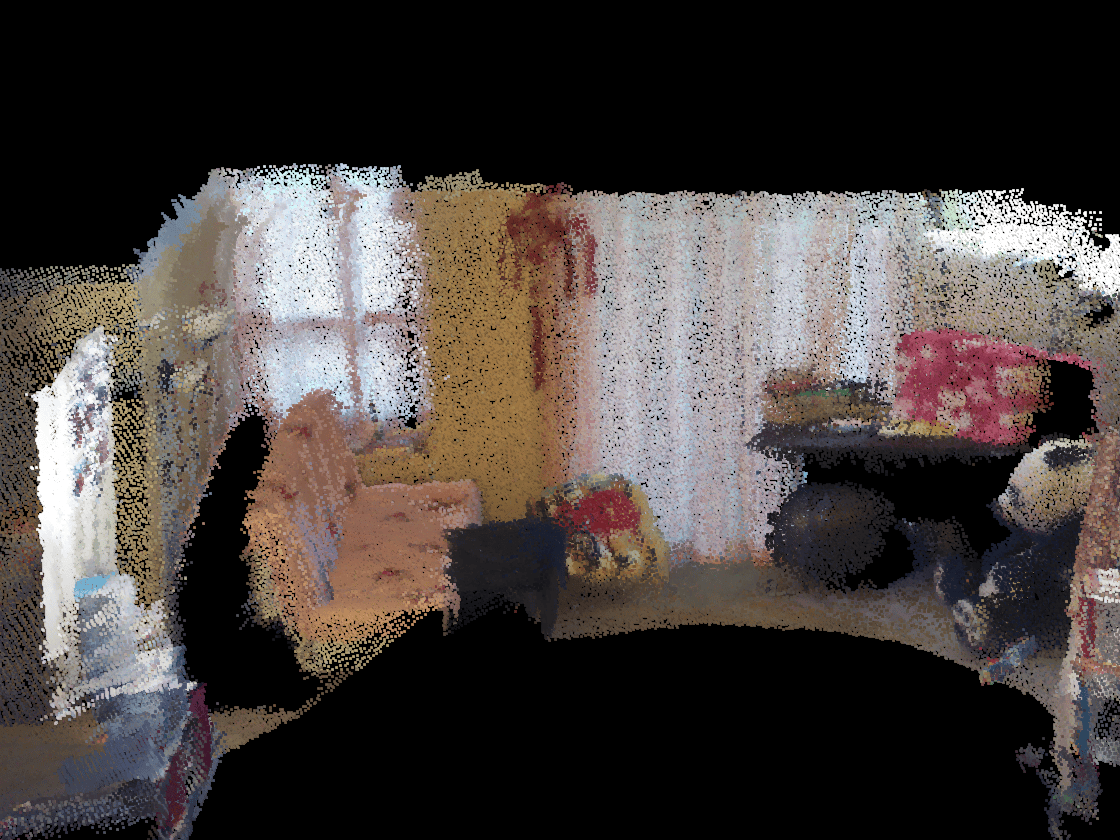
3차원 포인트 클라우드 정합 및 이어 붙이기
이 예제에서는 ICP(Iterative Closest Point) 알고리즘을 사용해 여러 포인트 클라우드를 결합하여 3차원 장면을 복원하는 방법을 보여줍니다. 그런 다음 포인트 클라우드의 색 정보를 활용하여 장면의 정확도를 높이는 방법을 보여줍니다.
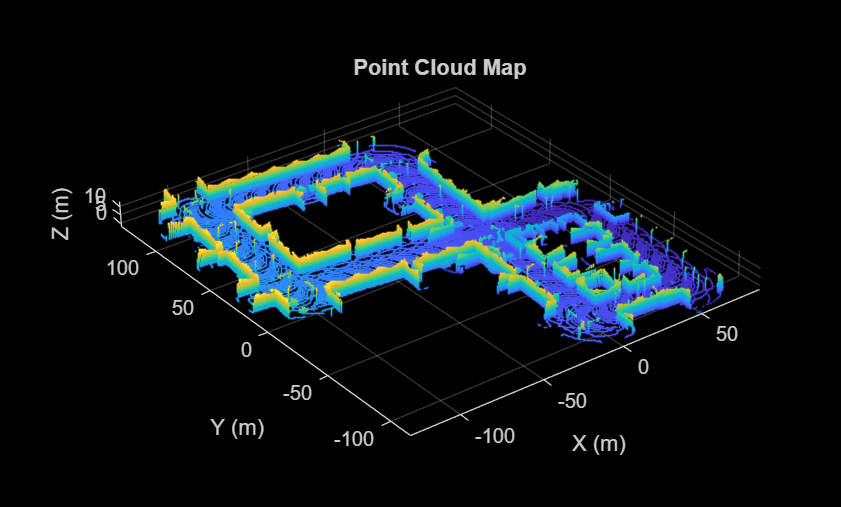
Design Lidar SLAM Algorithm Using Unreal Engine Simulation Environment
Record synthetic sensor data from a 3-D simulation environment, and develop a simultaneous localization and mapping (SLAM) algorithm using the recorded data.
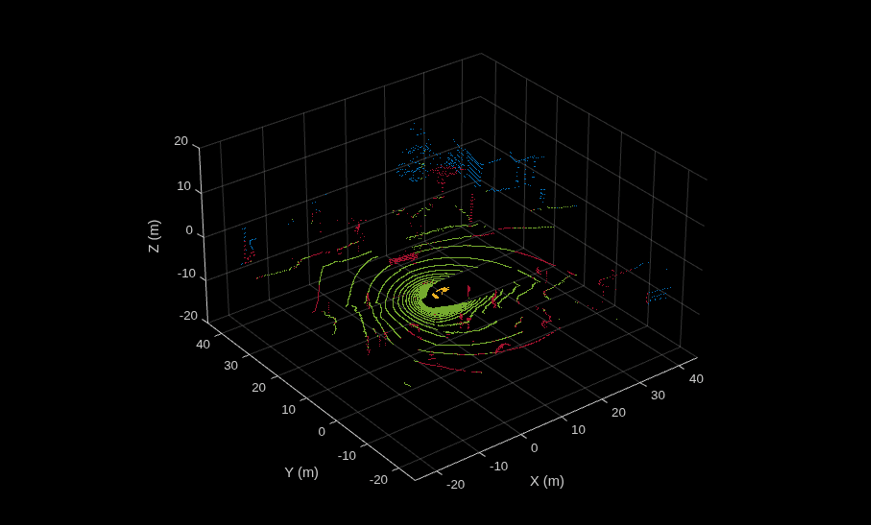
Ground Plane and Obstacle Detection Using Lidar
Process 3-D lidar data from a sensor mounted on a vehicle by segmenting the ground plane and finding nearby obstacles.

