중장비의 오프로드 자율성
R2026bRobotics System Toolbox™ Offroad Autonomy Library를 사용하여 건설업 응용 분야, 농업 응용 분야, 광업 응용 분야에서 오프로드 차량과 중장비를 위한 자율 시스템을 개발합니다. 이 지원 패키지는 자율 알고리즘을 설계하고, 시뮬레이션하며, 테스트하기 위한 전문 툴을 제공합니다. 이 지원 패키지는 Unreal Engine®과의 통합을 바탕으로 실사 시나리오 시뮬레이션을 통해 다양한 조건에서 덤프 트럭, 백호와 같은 오프로드 차량의 성능을 테스트하고 미세 조정할 수 있습니다.
Robotics System Toolbox Offroad Autonomy Library 지원 패키지를 다운로드하려면 Robotics System Toolbox Offroad Autonomy Library 지원 패키지 설치하기 항목을 참조하십시오.
Robotics System Toolbox를 통해 Unreal Engine을 사용하는 방법에 대한 자세한 내용은 Unreal Engine 시나리오 시뮬레이션 항목을 참조하십시오.
함수
블록
 | Simulation 3D Scene Configuration | Scene configuration for 3D simulation environment |
 | Simulation 3D Lidar | Lidar sensor model in 3D simulation environment (R2024a 이후) |
 | Simulation 3D Camera | Camera sensor model with lens in 3D simulation environment (R2024a 이후) |
 | Simulation 3D Agricultural Tractor | Agricultural tractor with ground following in 3D simulation environment (R2026b 이후) |
 | Simulation 3D Haul Truck | Haul truck with ground following in 3D simulation environment (R2026b 이후) |
 | Simulation 3D Physics Dump Truck | Dump truck physics model in 3D simulation environment (R2024a 이후) |
 | Simulation 3D Physics Backhoe | Backhoe physics model in 3D simulation environment (R2024b 이후) |
 | Four-Wheel Ground Following | Compute terrain-aligned 3-D pose for four-wheeled vehicle (R2026b 이후) |
 | Simulation 3D Four-Wheel Ground Following | Adjust vehicle chassis pose to align with terrain geometry (R2026b 이후) |
 | Chassis To Tree-Frame Motion | Transform motion from chassis frame to rigid body tree frame (R2026b 이후) |
 | Vehicle Wheel Joint Configuration | Compute wheel joint configuration for front-steered vehicle wheel spin visualization (R2026b 이후) |
 | Bicycle MPPI Controller | Control motion planning of bicycle vehicle model using Model Predictive Path Integral (MPPI) (R2025a 이후) |
 | Ackermann MPPI Controller | Control motion planning of Ackermann vehicle model using Model Predictive Path Integral (MPPI) (R2025a 이후) |
 | Differential Drive MPPI Controller | Control motion planning of differential drive vehicle model using Model Predictive Path Integral (MPPI) (R2025a 이후) |
 | Articulated Steering MPPI Controller | Control motion planning of articulated steering vehicle model using Model Predictive Path Integral (MPPI) (R2025b 이후) |
장면
| 오프로드 노천 채굴 장면 | Offroad pit mining scene in Unreal Engine environment |
| 건설 현장 장면 | Construction site scene in Unreal Engine environment |
| 구릉지 포도밭 | Vineyard on rolling hills in Unreal Engine environment |
도움말 항목
오프로드 차량 라이브러리
- Offroad Vehicle Library
Predefined offroad vehicle models for simulation and autonomy workflows (R2026b 이후) - Plan and Follow Path with Offroad Vehicle
Load a vehicle from the Offroad Vehicle Library, plan a collision-free path, and follow it using an MPPI controller. (R2026b 이후)
참조 응용 사례
- Offroad Navigation for Autonomous Haul Trucks in Open Pit Mine
Series shows how to create a set of planners to enable autonomous haul trucks to navigate uneven terrain and avoid obstacles. (R2024a 이후)
- 단계 1: Create Route Planner for Offroad Navigation Using Digital Elevation Data
- 단계 2: Create Onramp and Terrain-Aware Global Planners for Offroad Navigation
- 단계 3: Navigate Global Path Through Offroad Terrain Using Local Planner
- 단계 4: Create Path Following Model Predictive Controller
- 단계 5: Model and Control Autonomous Vehicle in Offroad Scenario
경로 추종 항목
- Introduction to Model Predictive Path Integral (MPPI) Controller
Path planning using Model Predictive Path Integral (MPPI) with adaptable vehicle models. (R2026a 이후)
지원 패키지 설정
- Robotics System Toolbox Offroad Autonomy Library 지원 패키지 설치하기
오프로드 중장비용 알고리즘을 설계하고, 시뮬레이션하며, 검증하기 위한 애드온을 사용합니다.
추천 예제
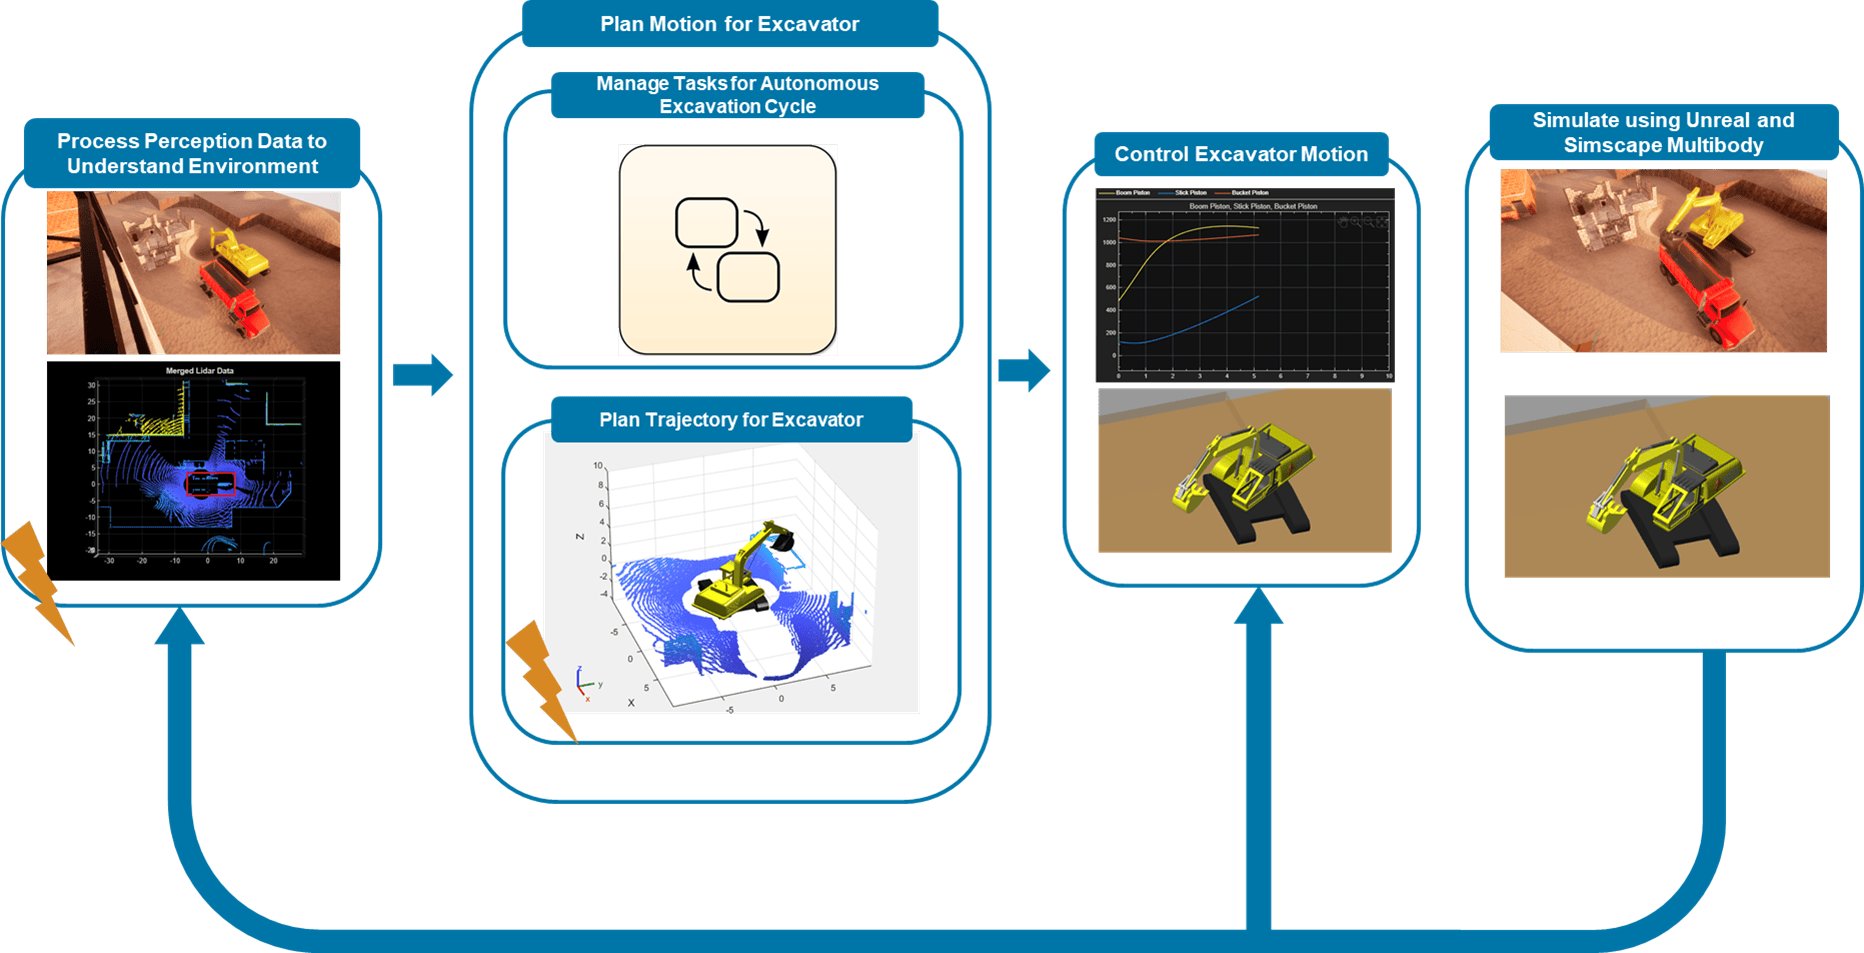
Simulate Earth Moving with Autonomous Excavator in Construction Site
Simulate ground excavation to create a depression and move spoil to dump truck and further relocate it to another site.
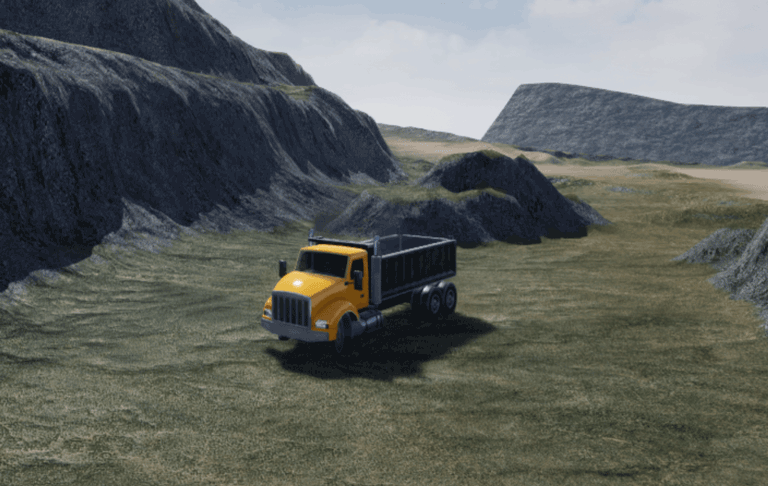
Offroad Navigation for Autonomous Haul Trucks in Open Pit Mine
Series shows how to create a set of planners to enable autonomous haul trucks to navigate uneven terrain and avoid obstacles.
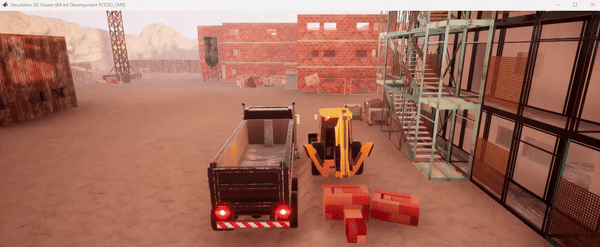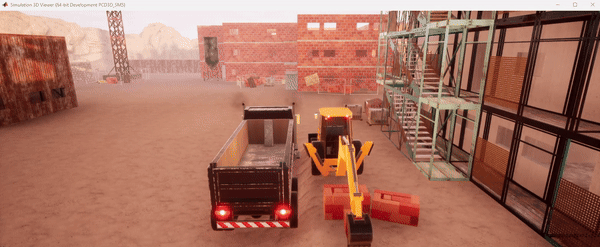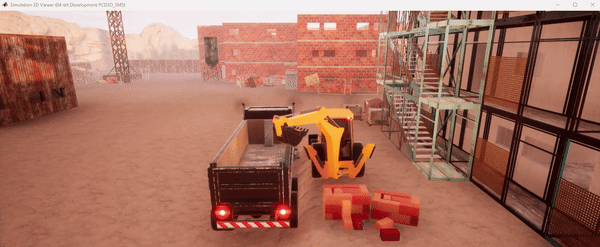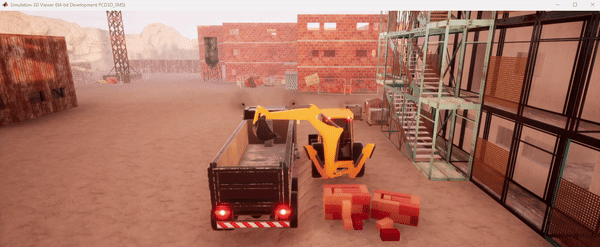
Simulate Construction Vehicles in Unreal Engine for Material Handling
Set up a simulation in which backhoe loads construction bricks into a dump truck in an Unreal Engine construction site scene.
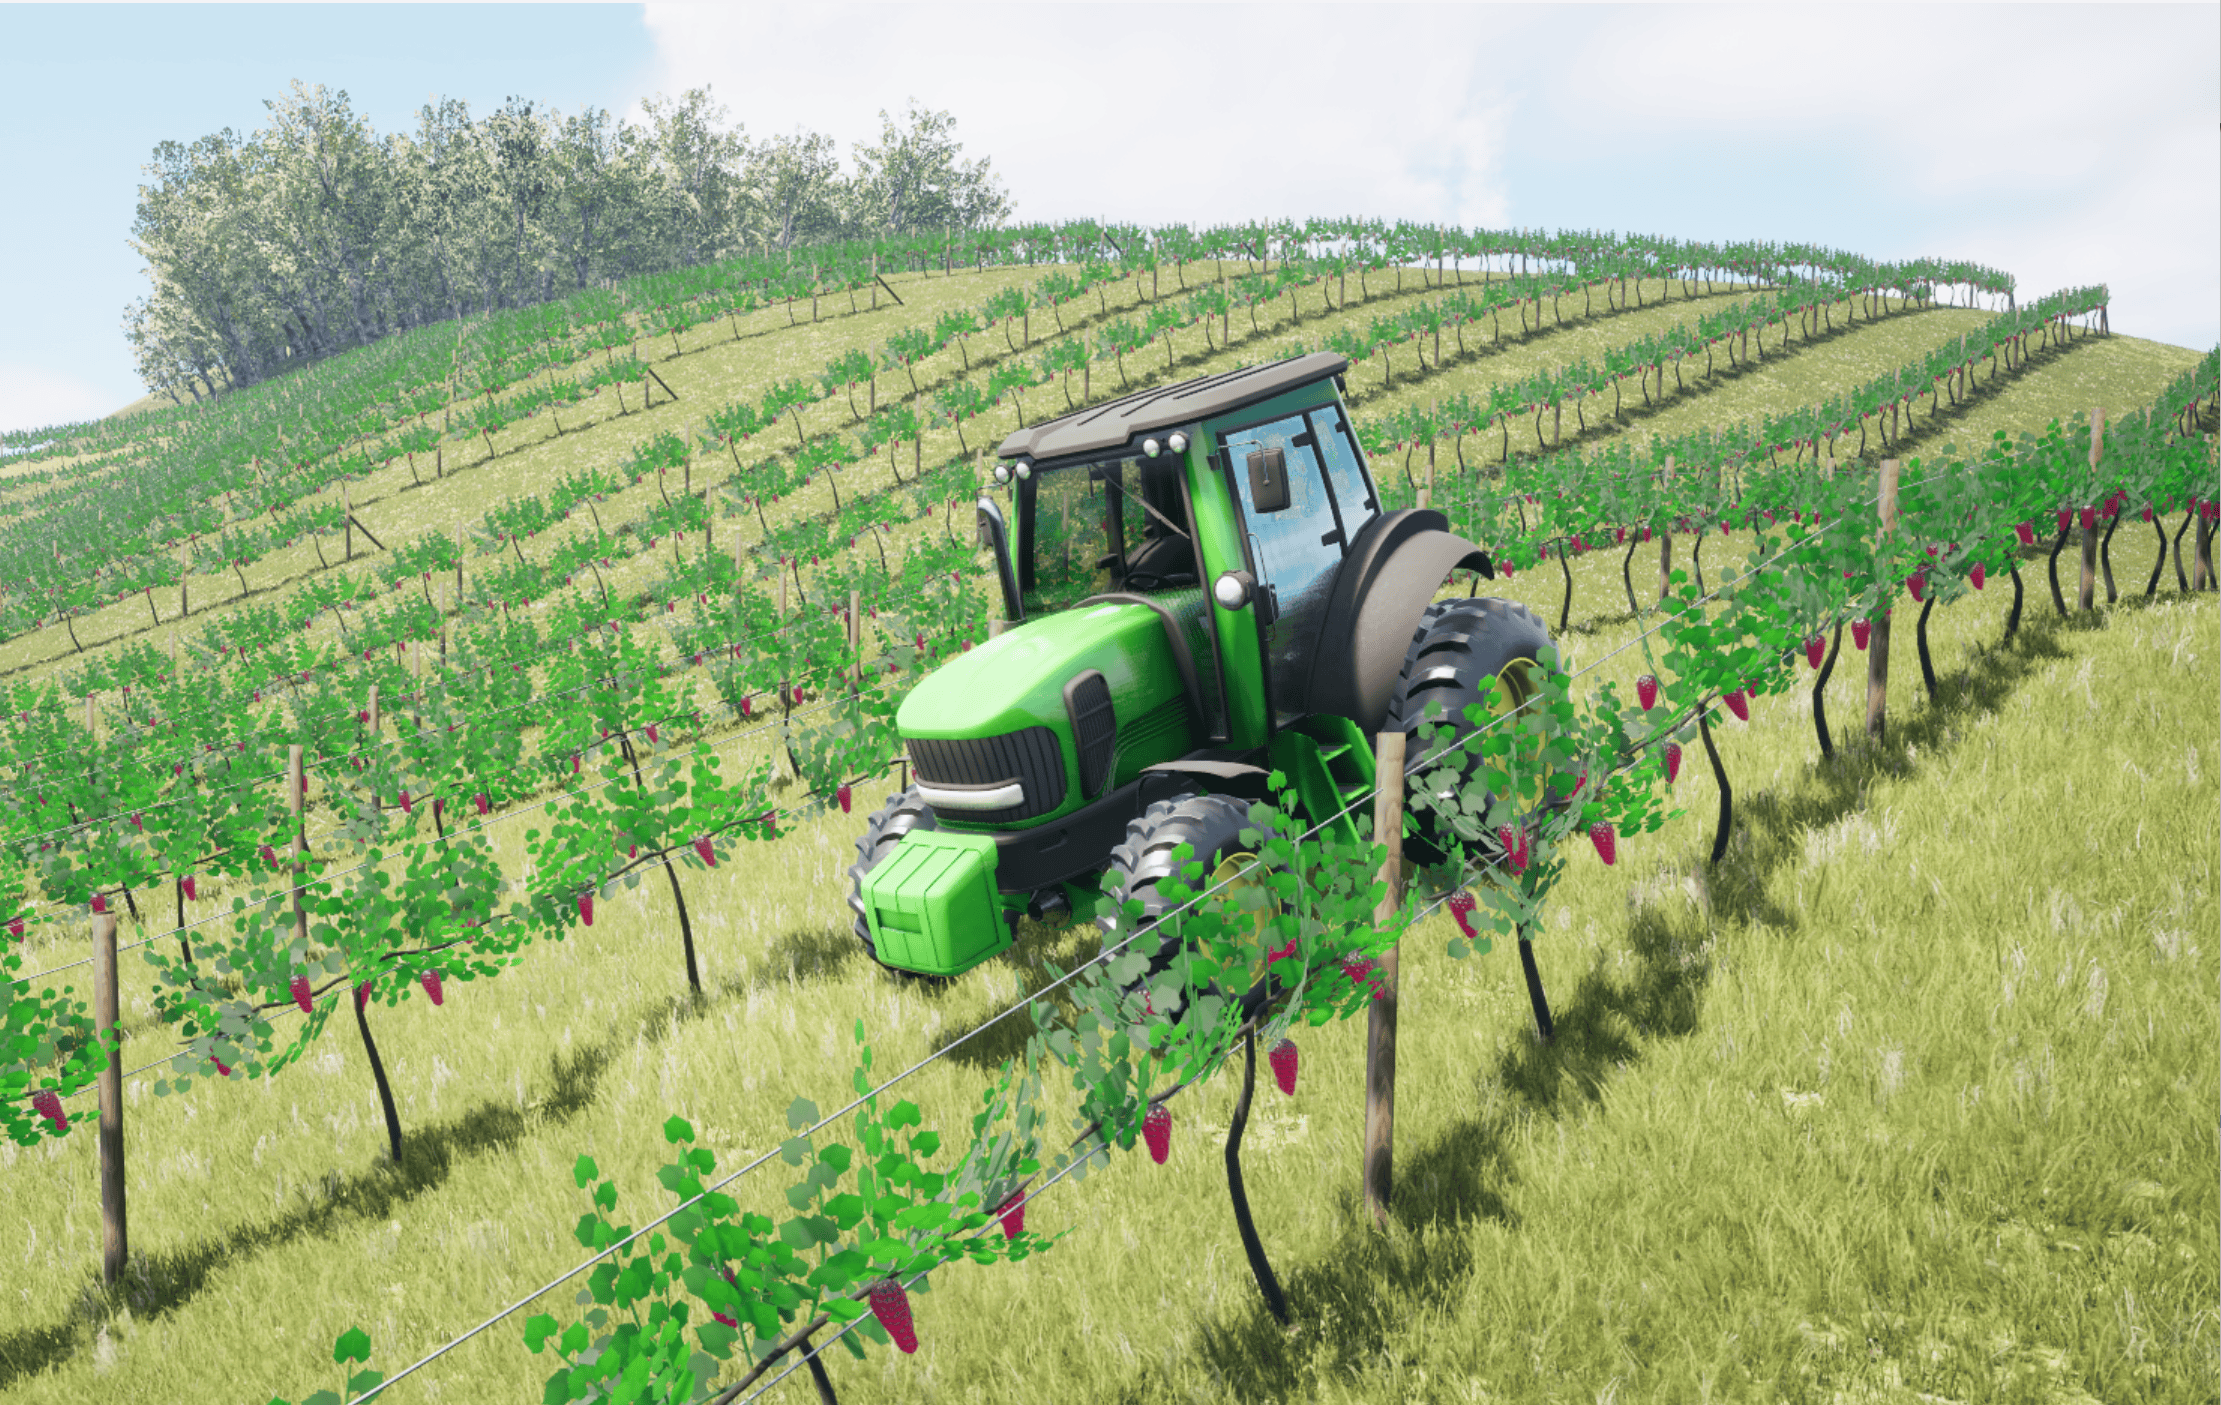
Drive Agricultural Tractor in Vineyard Using Unreal Engine
Drive an agricultural tractor through a vineyard scene in Unreal Engine.
Generate Synthetic Sensor Data for Localization Using Unreal Engine
Simulate IMU and monocular camera data in Unreal Engine to develop and validate state estimation algorithms.
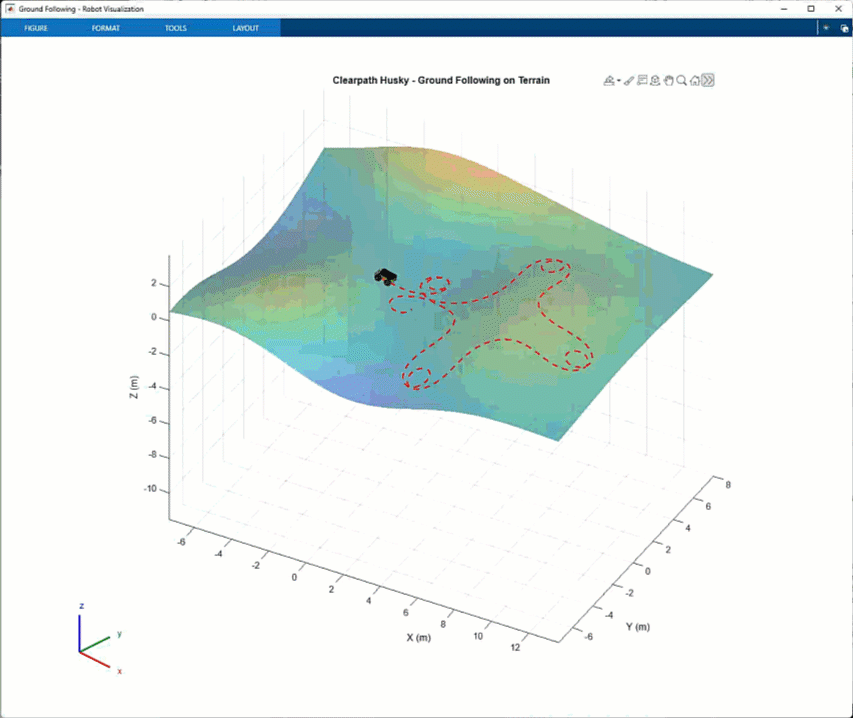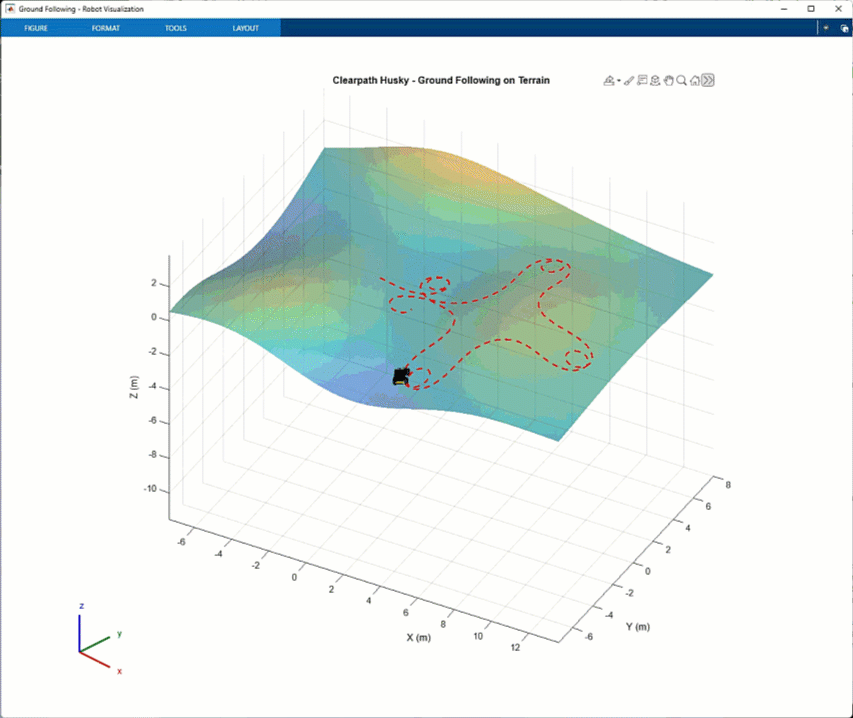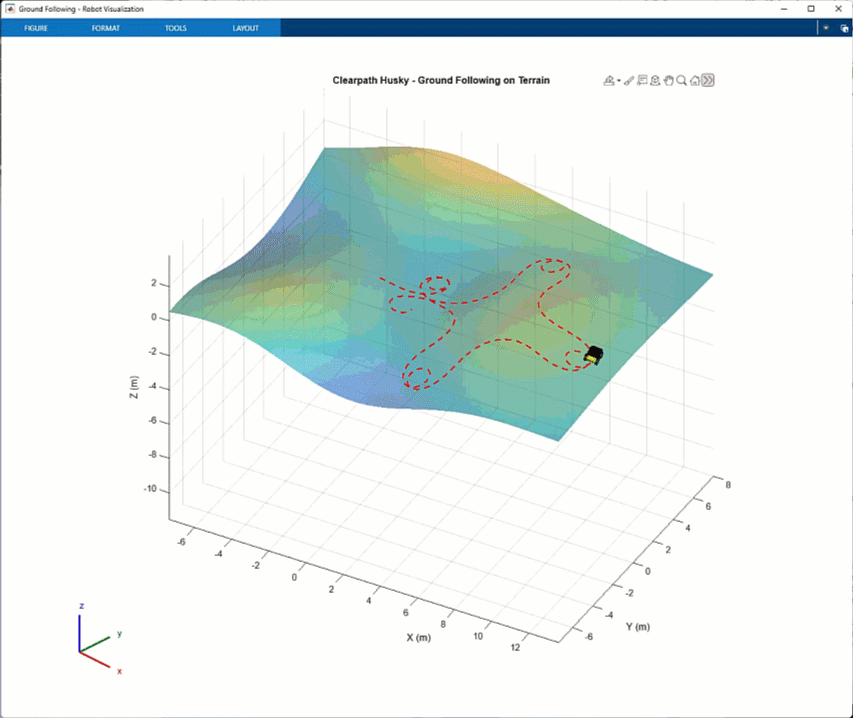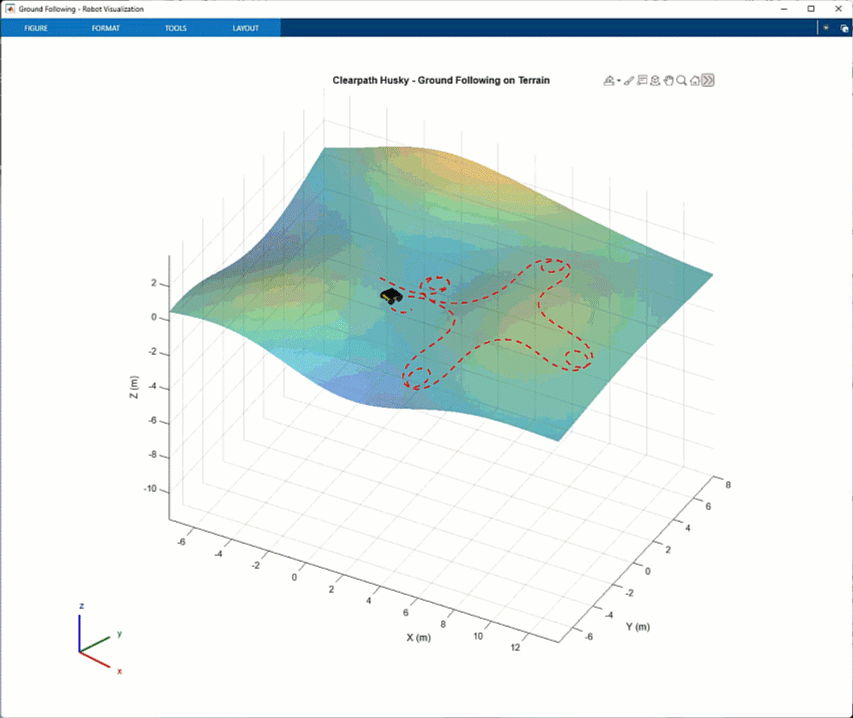
Simulate Ground Following and Visualize Robot on Terrain
Simulate a four-wheeled robot following terrain and visualize the robot animation on the terrain surface, without requiring Unreal Engine or any 3-D simulation environment.
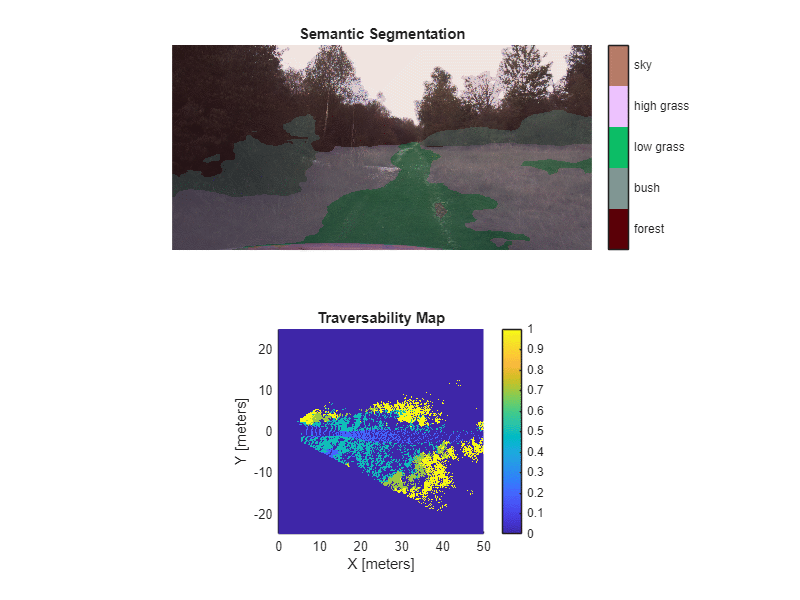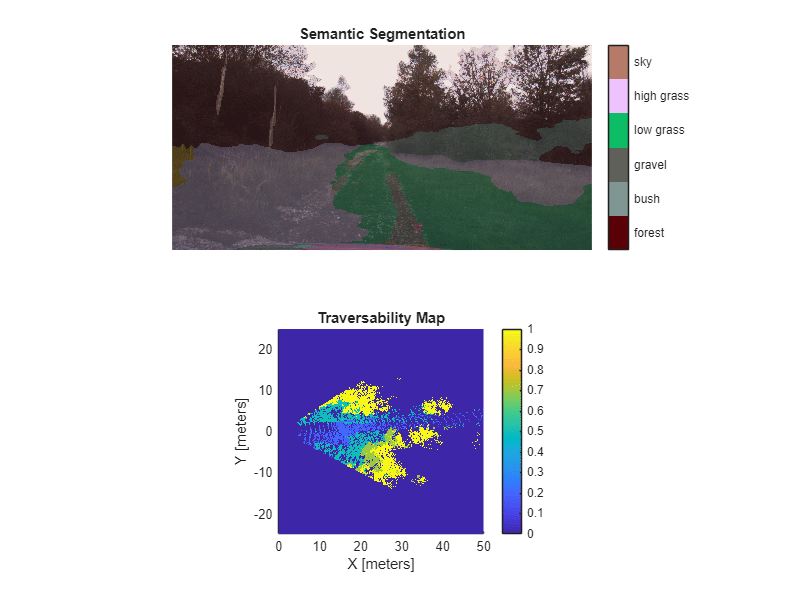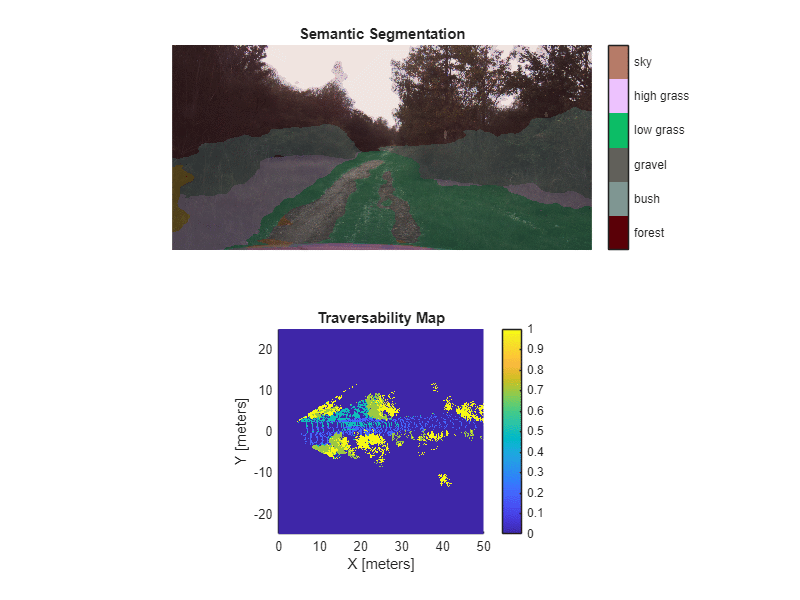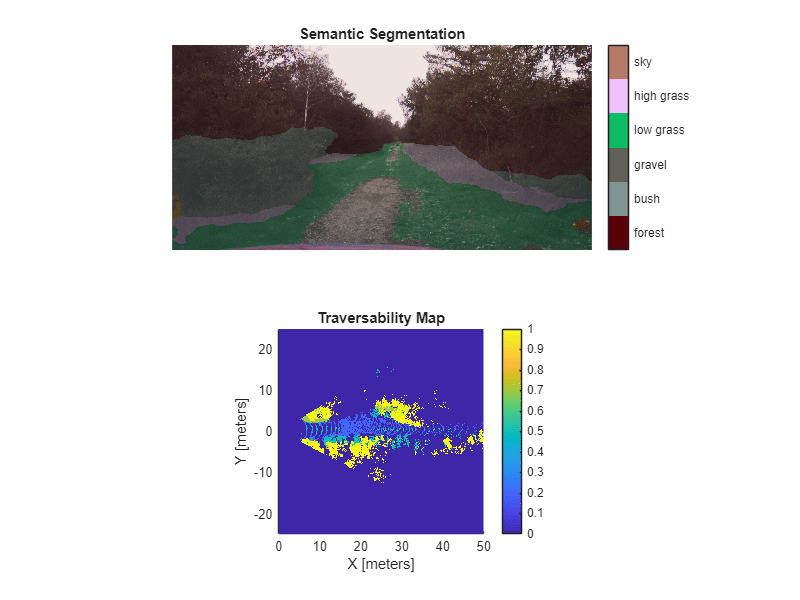
Generate Traversability Map for Offroad Terrain Using Semantic Segmentation
Create real-time traversability map for offroad terrain by fusing semantic segmentation from camera images with lidar point clouds.
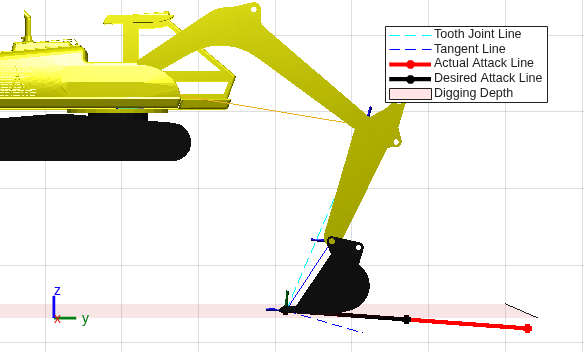
Constrain Links of Excavator for Earth Moving
Solve joint angles for excavator digging, grading, and unloading trajectories with GIK.
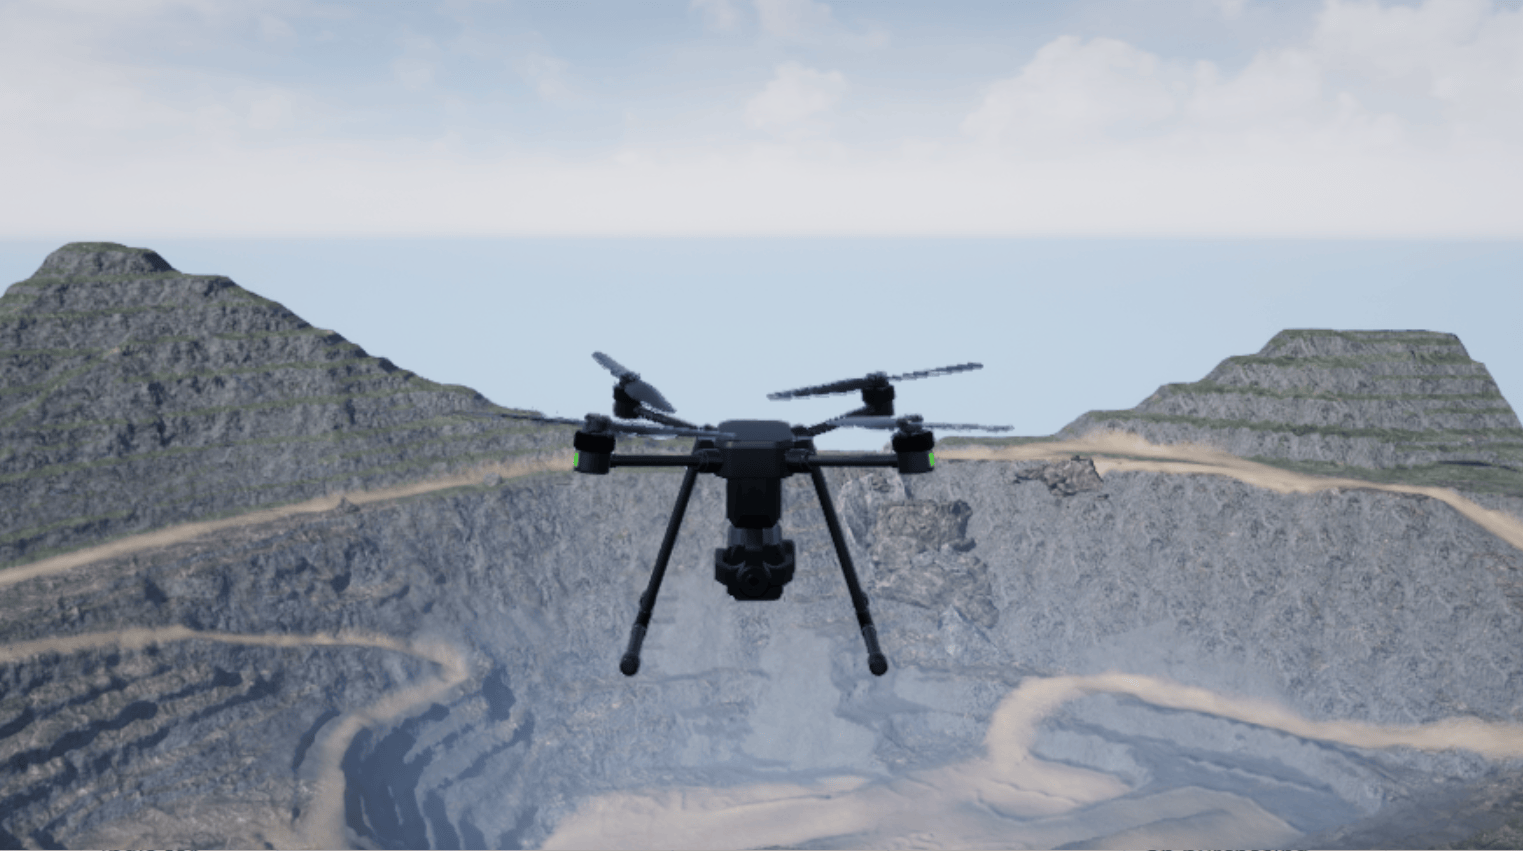
Survey Pit Mining Site with RTK GPS and Point Clouds
Generate a digital elevation model (DEM) of a site using real-time kinematic (RTK) GPS and aerial lidar data.

