이 번역 페이지는 최신 내용을 담고 있지 않습니다. 최신 내용을 영문으로 보려면 여기를 클릭하십시오.
PX4를 사용한 Hardware-in-the-Loop 시뮬레이션(HITL)
R2026aPX4를 사용한 Hardware-in-the-Loop 시뮬레이션(HITL)의 작동 방법을 알아봅니다. 다음 항목은 HITL 아키텍처, 물리 연결, HITL 설정에 대해 알아보는 데 도움이 됩니다.
도움말 항목
- PX4 Hardware-in-the-Loop System Architecture
Details about PX4® HITL architecture and physical connections required to set up HITL.
- Setting Up PX4 Autopilot in Hardware-in-the-Loop (HITL) Mode from QGroundControl
Set up PX4 Autopilot in HITL mode from QGC.
- Set Up PX4 Firmware for Hardware-in-the-Loop (HITL) Simulation
Set up PX4 Firmware using hardware setup screens for HITL simulation.
- Configure Simulink Model for Deployment in Hardware-in-the-Loop (HITL) Simulation
Set up controller model in HITL mode.
- Configure Simulink Model for Monitor & Tune Simulation with Hardware-in-the-Loop (HITL)
Set up controller model for Monitor & Tune in HITL mode.
- MAVLink Connectivity for QGC, On-board Computer and Simulink Plant
Routing MAVLink data from Pixhawk® to QGC and Simulink Plant.
- Fixed-Wing Plant and Controller Architecture
PX4 HITL Fixed-Wing Plant and controller high level summary.
- PX4 Hardware-in-the-Loop (HITL) Simulation with Fixed-Wing Plant and Hardcoded Mission in Simulink
PX4 HITL Fixed-Wing Plant and executing hardcoded mission in Simulink®.
- PX4 Hardware-in-the-Loop (HITL) Simulation with Manual Control for Fixed-Wing Plant in Simulink
PX4 HITL Fixed-Wing Plant with manual control in Simulink.
- Set Up Speedgoat for HITL Simulation with PX4
Set up Speedgoat® and its connected hardware for hardware-in-the-loop simulation with PX4.
추천 예제
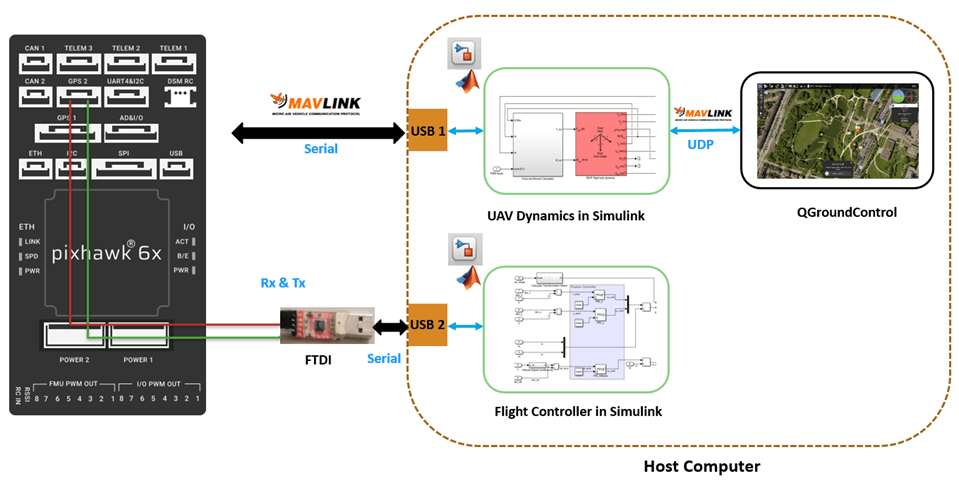
Run PX4 Autopilot in Hardware-in-the-Loop (HITL) Simulation with UAV Dynamics in Simulink
Verify a controller design by deploying on Pixhawk® hardware board in Hardware-in-the-Loop (HITL) mode. Hardware-in-the-Loop (HITL or HIL) is a simulation mode in which normal PX4 firmware is run on real flight controller hardware. This approach lets you test most of the actual flight code on the real autopilot hardware, while the UAV dynamics in Simulink®. To understand the physical connections required to set up the Pixhawk and Simulink for HITL Simulation, go through the PX4 Hardware-in-the-Loop System Architecture.
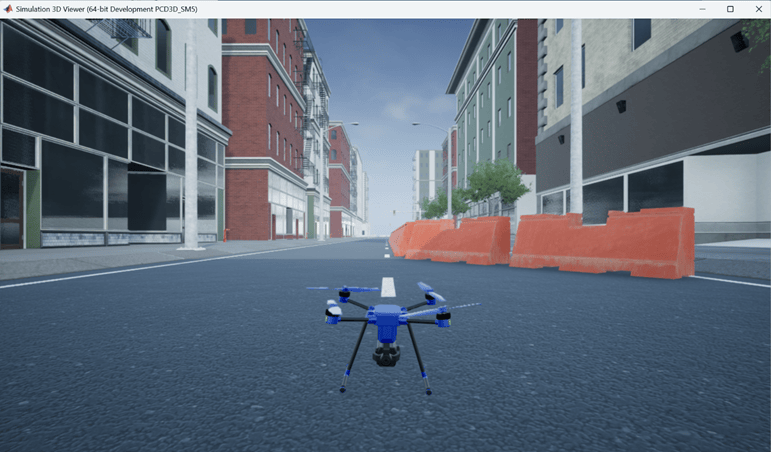
Visualize PX4 Hardware-in-the-Loop (HITL) Simulation with UAV Dynamics in Simulink
Run PX4 HITL simulation with quadcopter plant in Simulink and visualize using Unreal Engine or 3D Scenarios.
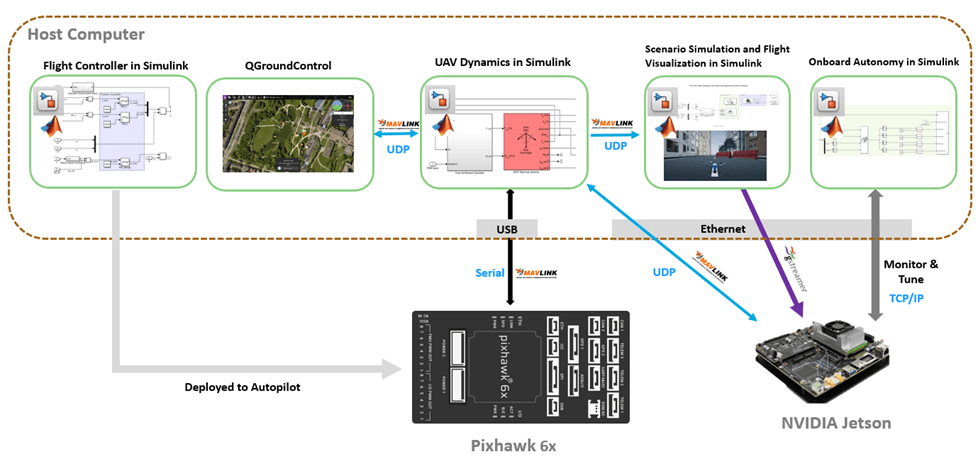
PX4 Autopilot Simulation with UAV Dynamics Modeled and Unreal Engine Flight Visualization
Use the UAV Toolbox Support Package for PX4® Autopilots to verify a flight controller deployed on a Pixhawk® flight controller in Hardware-in-the-Loop (HITL) simulation with UAV dynamics modeled in Simulink®.
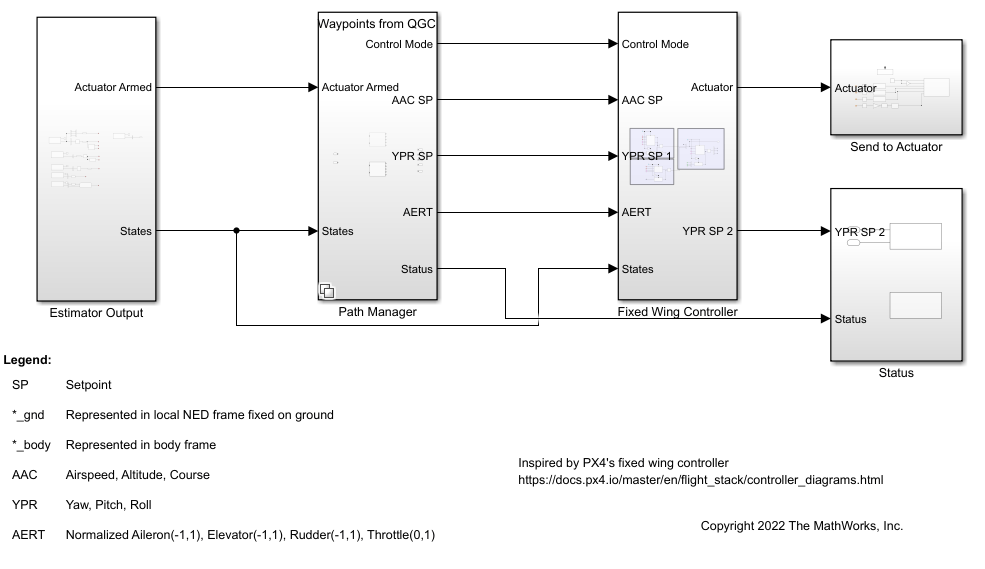
PX4 Hardware-in-the-Loop (HITL) Simulation with Fixed-Wing Plant in Simulink
Use the UAV Toolbox Support Package for PX4® Autopilots to verify the controller design by deploying the design on the PX4 Autopilot hardware board. This is done in HITL mode with fixed-wing UAV Dynamics contained in Simulink®.
UVify IFO-S Autopilot in Hardware-in-the-Loop (HITL) Simulation in Simulink
Use the UAV Toolbox Support Package for PX4® Autopilots to deploy and verify algorithms on UVify IFO-S Drone, with NVIDIA® Jetson™ as Onboard computer. This example shows how to use the UAV Toolbox Support Package for PX4® Autopilots to deploy and verify flight control algorithms on a UVify IFO-S Autopilot using Hardware-in-the-Loop (HITL) simulation in Simulink®.
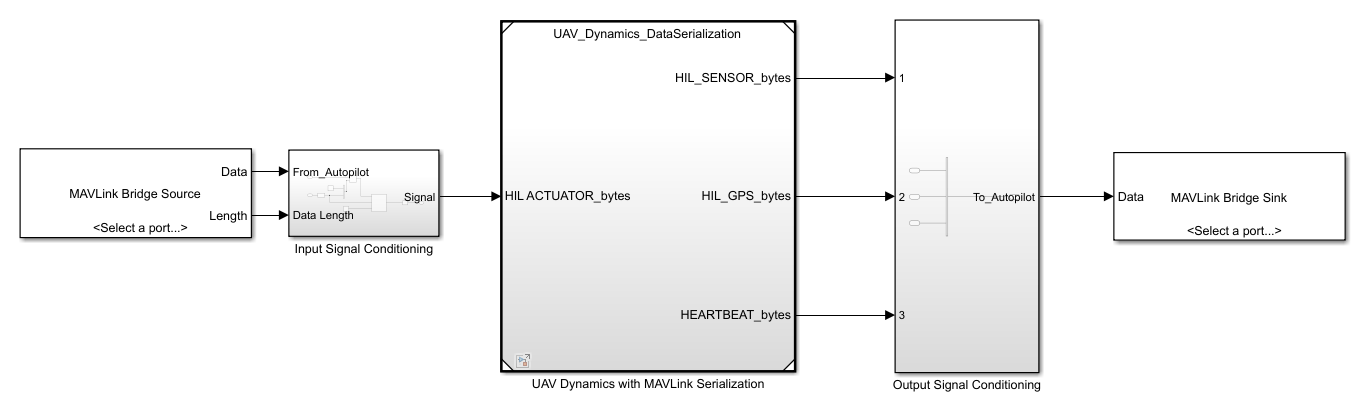
PX4 Stock Autopilot in HITL Simulation with UAV Dynamics Modeled in Simulink
Use the UAV Toolbox Support Package for PX4® Autopilots to design UAV Dynamics in Simulink® and verify them by using the PX4 Stock Autopilot in HITL mode.

