이 번역 페이지는 최신 내용을 담고 있지 않습니다. 최신 내용을 영문으로 보려면 여기를 클릭하십시오.
모션 계획
R2026a제약 조건과 비용 최적화가 적용된 비행 궤적을 생성합니다. UAV 임무를 위해 장애물 회피를 수행합니다. 궤적을 3차원 시뮬레이션 환경으로 가져옵니다.
객체
함수
블록
 | Obstacle Avoidance | Compute obstacle-free direction using range sensor data and target position |
 | Minimum Jerk Polynomial Trajectory | Generate minimum jerk polynomial trajectories through multiple waypoints (R2022a 이후) |
 | Minimum Snap Polynomial Trajectory | Generate minimum snap polynomial trajectories through multiple waypoints (R2022a 이후) |
 | Read UAV Trajectory | Generate translation and rotation samples from UAV trajectory for 3D simulation (R2024b 이후) |
도움말 항목
- Simulate UAV Mission in Urban Environment
Simulate a UAV mission in an urban environment using UAV scenario and OpenStreetMap® data of Manhattan, New York.
- Generate Random 3-D Occupancy Map for UAV Motion Planning
This example shows how to generate a random 3D occupancy map by automatically adding the desired number of obstacles of varying dimensions at random positions on the map.
- Simulate UAV Scenario Trajectory in Unreal Engine Environment
Design a flight trajectory in a UAV scenario, and simulate the trajectory in a 3D environment using Unreal Engine®.
- Design Real-World Trajectory in UAV Scenario and Visualize with Cesium
Design a real-world trajectory in a UAV scenario, and visualize the trajectory in a 3D environment using Cesium.
- Simulate Flight Plan in Real-World Location Using Cesium
Simulate a flight plan created with QGroundControl in a 3D environment using Cesium.
추천 예제
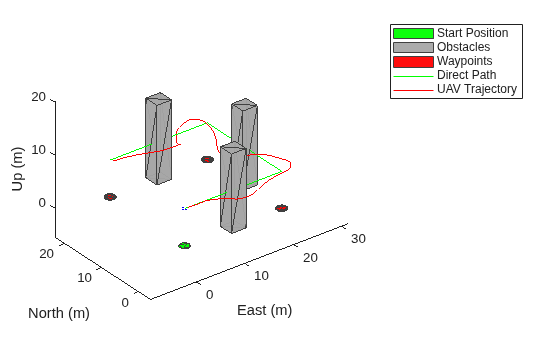
UAV Obstacle Avoidance in Simulink
Simulate a waypoint following mission with obstacles using the 3D VFH+ algorithm to compute an obstacle-free path.
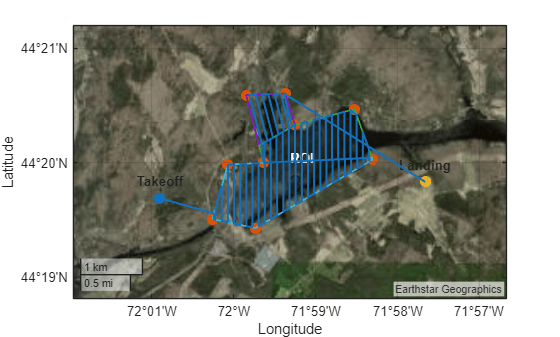
Optimally Survey and Customize Coverage of Region of Interest
Plan and customize a coverage path for a UAV to use to survey a geographical region.
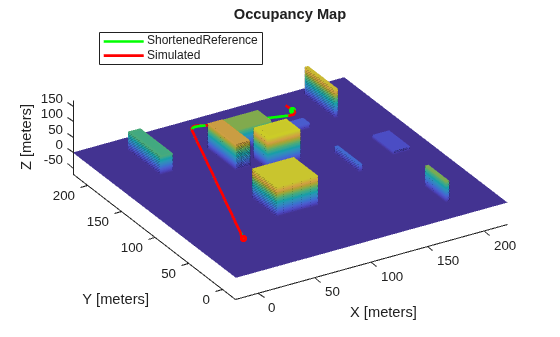
Motion Planning with RRT for Fixed-Wing UAV
Plan the 3D motion of a fixed-wing UAV using the rapidly exploring random tree (RRT) algorithm, given a start and goal pose.
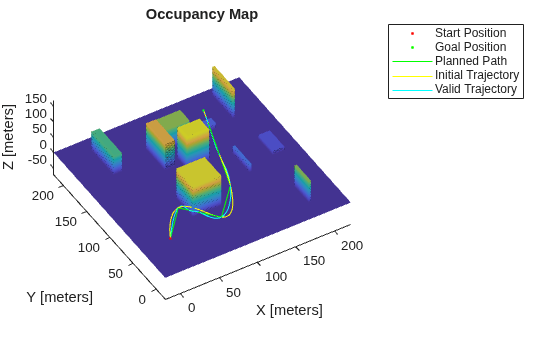
Plan Minimum Snap Trajectory for Quadrotor
Plan a 3D minimum snap trajectory for a multirotor UAV from a start to a goal pose by using the RRT* path planner.
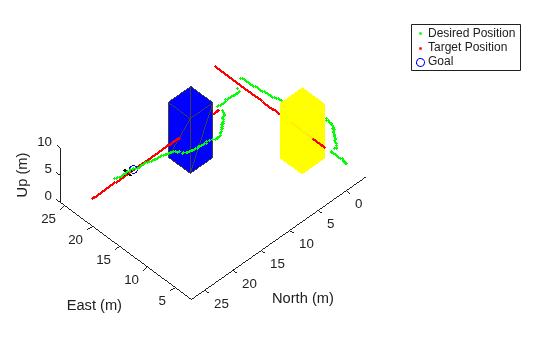
Tune 3D Vector Field Histogram Controller for Obstacle Avoidance
Tune the controllerVFH3D System object™ to navigate a multirotor UAV in an obstacle environment using a lidar sensor.
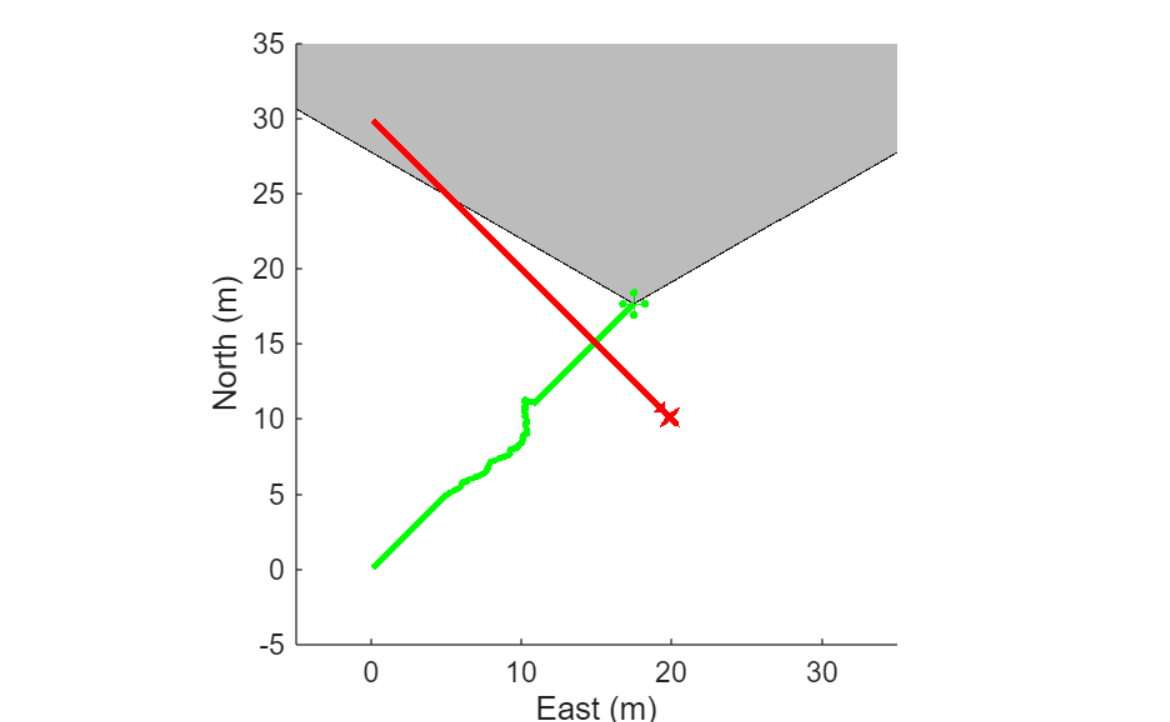
Simulate UAV Using Radar Sensor to Avoid Dynamic Obstacle
Avoid collision with moving obstacles, based on the velocity obstacle algorithm by using radar detections.

