이 번역 페이지는 최신 내용을 담고 있지 않습니다. 최신 내용을 영문으로 보려면 여기를 클릭하십시오.
유도항법제어
R2026a유도 모델 객체와 블록을 사용해 환경 및 제어 입력의 영향을 받는 고정익 및 멀티로터 UAV 모델의 상태 벡터를 계산할 수 있습니다. 내비게이션 알고리즘을 사용하여 임무 중에 UAV 경로를 관리하고 웨이포인트 추종 및 선회 임무에 대한 제어 입력을 계산할 수 있습니다.
객체
함수
블록
 | Path Manager | Compute and execute a UAV autonomous mission |
 | Orbit Follower | Orbit location of interest using UAV |
 | Waypoint Follower | Follow waypoints for UAV |
 | Guidance Model | Reduced-order model for UAV |
 | Multi-Instance Guidance Model | Simulate multiple UAVs with reduced-order guidance models (R2025a 이후) |
 | Fixed-Wing UAV Point Mass | Integrate fourth- or sixth-order point mass equations of motion in coordinated flight |
도움말 항목
- Simulate Multiple Fixed-Wing UAVs in Simulink Using System Objects
Simulate multiple UAVs flying in a waypoint following mission using Simulink®.
- Improve UAV Position Estimation with Kalman Filter
Create a basic Kalman Filter to estimate UAV position.
- UAV Navigation in Unknown Environment with 2D Lidar SLAM
Simultaneously navigate and create map of an unknown environment using 2D LIDAR SLAM.
- Tune Control Design for VTOL UAV in Hover Configuration
Tune the hover flight control of a VTOL UAV.
- Tune Hover Control Design for VTOL UAV in Steady Wind Condition
Tune the hover flight control of a VTOL UAV in steady wind conditions.
- Multiloop Control Design for VTOL UAV in Fixed Wing Configuration
Tune the fixed-wing flight controller of a VTOL UAV.
- Tune Control Design for VTOL UAV in Transition
Tune the transition controller of a VTOL UAV for transitioning between hovering and fixed-wing flight.
추천 예제
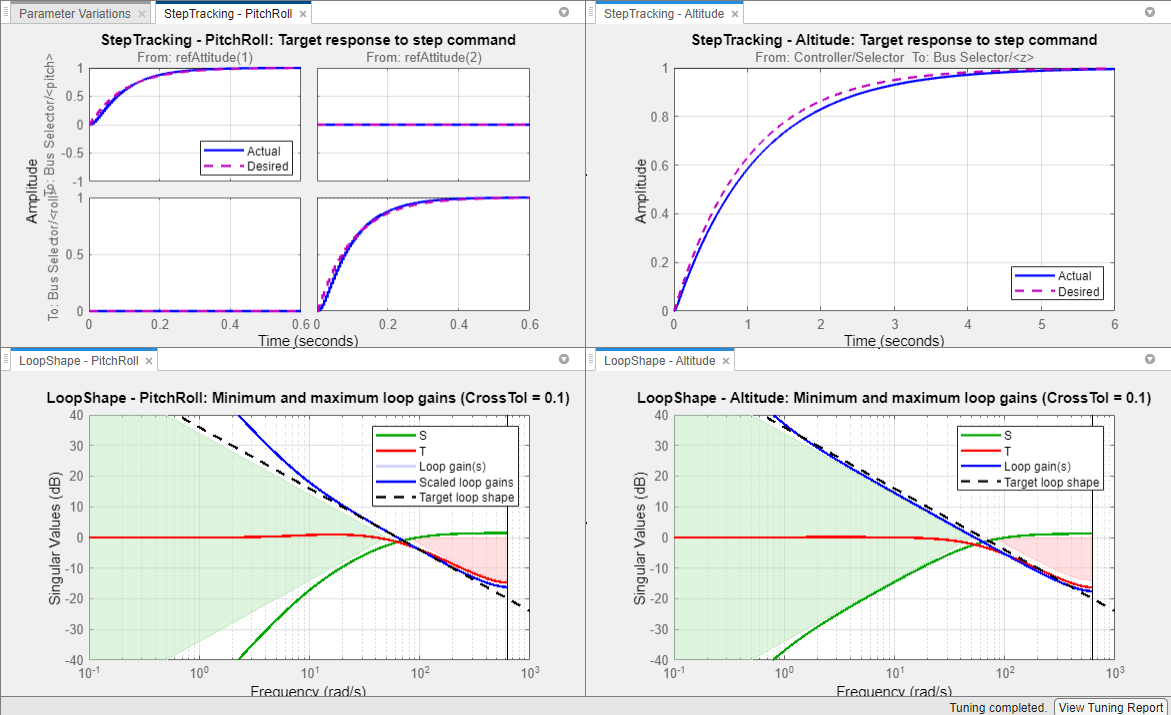
UAV In-flight Failure Recovery
Use Control System Tuner to tune the fixed-structure PID controllers of a multicopter for nominal flight conditions and fault conditions. Here, you use a gain-scheduled approach to recover from a single rotor failure and land the UAV.
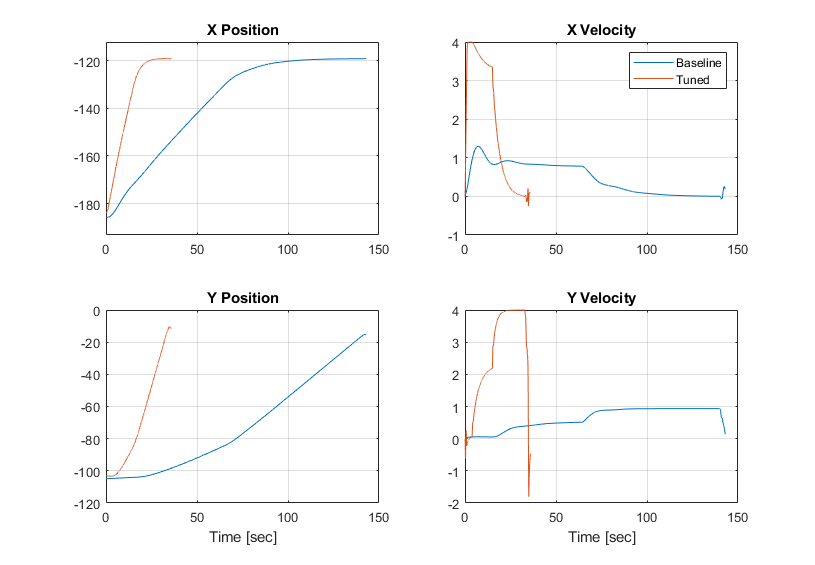
Automatically Tune Quadcopter PID Gains to Reduce Mission Time
Tune quadcopter attitude and position PID controllers by using the Closed-Loop PID Autotuner block.
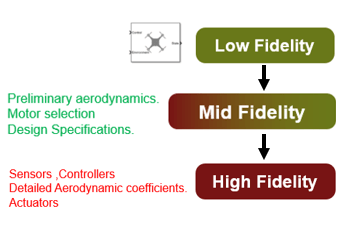
Evolve UAV Plant Model from Low to High Fidelity
Evolve your UAV plant model continuously to stay in sync with the latest information available.
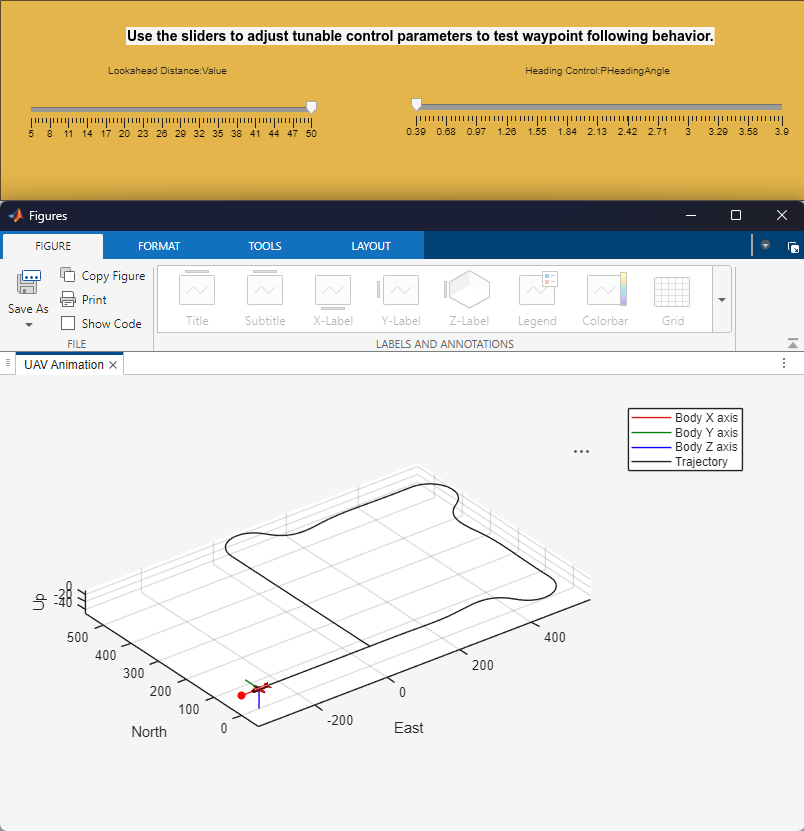
Tuning Waypoint Following Controller for Fixed-Wing UAV
Design and tune a waypoint following controller for a fixed-wing UAV by using the Guidance Model and Waypoint Follower blocks.
Control a Simulated UAV Using ROS 2 and PX4 Bridge
Receive sensor readings and autopilot status from PX4® autopilot and send control commands to navigate a simulated UAV.

UAV Guidance Model 블록을 사용하여 고충실도 UAV 모델 근사하기
UAV를 위한 차수 축소 모델을 사용하여 웨이포인트 추종 내비게이션 시스템을 프로토타이핑하고 조정합니다.

