이 번역 페이지는 최신 내용을 담고 있지 않습니다. 최신 내용을 영문으로 보려면 여기를 클릭하십시오.
필터링, 변환, 기하학적 연산
R2026aLidar Toolbox™ 함수를 사용하여 원시 포인트 클라우드 데이터를 더 쉽게 분석할 수 있는 형식으로 변환합니다. 다운샘플링과 잡음 제거를 포함한 필터링 알고리즘을 적용하고, 포인트 클라우드 데이터를 곡면 메시나 DEM(Digital Elevation Model: 수치 표고 모델)으로 변환하고, 평면이나 직육면체와 같은 기하 모델을 포인트 클라우드 데이터에 피팅할 수 있습니다.
포인트 클라우드 분석기 앱을 사용하여 대화형 방식으로 포인트 클라우드 데이터를 시각화, 처리 및 분석할 수도 있습니다. 자세한 내용은 Get Started with Point Cloud Analyzer 항목을 참조하십시오.
앱
| 포인트 클라우드 분석기 | View, edit, and analyze point cloud data |
함수
도움말 항목
- Introduction to Lidar
High-level overview of lidar concepts and applications.
- Coordinate Systems in Point Cloud Toolbox
Overview of coordinate systems in Point Cloud Toolbox™.
- What Are Organized and Unorganized Point Clouds?
Define unorganized and organized point clouds and how to convert the former to latter.
- Get Started with Point Cloud Analyzer
Interactively visualize and analyze point cloud data.
- Create Custom Preprocessing Algorithm with Point Cloud Analyzer
Create a custom algorithm to preprocess the input point cloud using the Point Cloud Analyzer app.
- 특징을 사용하여 두 포인트 클라우드 간의 변환 추정
이 예제에서는 두 포인트 클라우드 간의 강체 변환을 추정하는 방법을 보여줍니다.
- Estimate Stockpile Volume from Aerial Lidar Data
This example shows how to estimate the volume of a stockpile from aerial point cloud data.
- Colorize Aerial Point Cloud Using Aerial Image
Fuse the color from an aerial image onto aerial point cloud data using Coordinate Reference System (CRS) information. (R2025a 이후)
- Compare Point Clouds in Point Cloud Analyzer
Compare point clouds to detect changes using Point Cloud Analyzer app. (R2026b 이후)
추천 예제
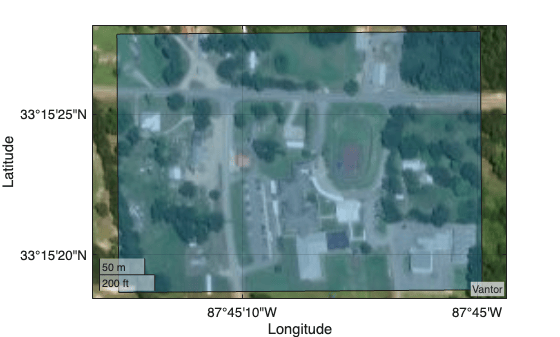
Visualize Point Clouds on Maps Using Coordinate Reference System from LAS/LAZ Files
Transform a point cloud between coordinate reference systems.
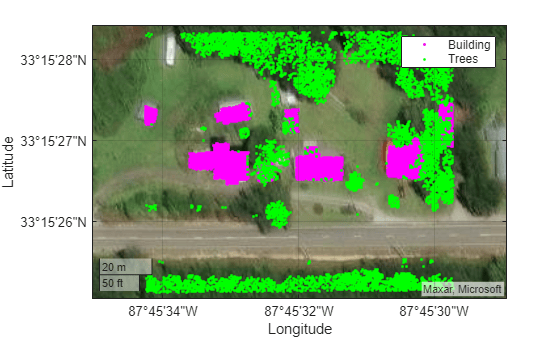
Export Point Cloud Segmentations to KML Files
Export segmented point cloud data to Keyhole Markup Language (KML) files and read and visualize the KML data using different tools.
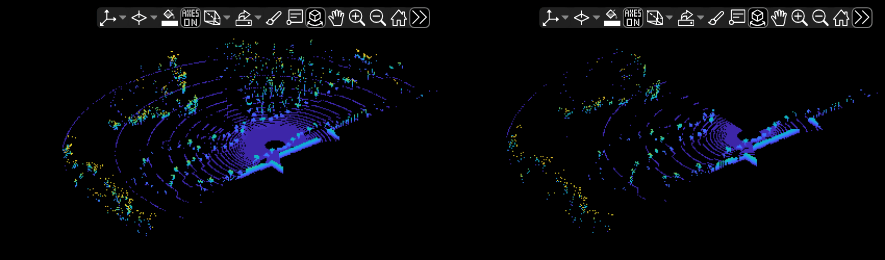
Unorganized to Organized Conversion of Point Clouds Using Spherical Projection
Convert unorganized point clouds to organized format using spherical projection.
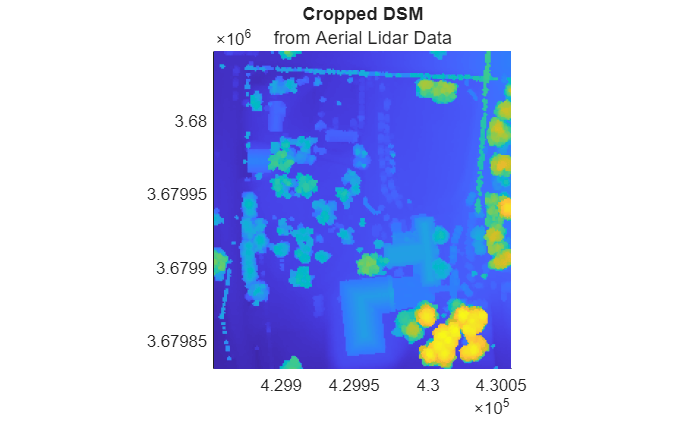
Create, Process, and Export Digital Surface Model from Lidar Data
Process aerial lidar data received from an airborne lidar system into a GeoTIFF file. Import a LAZ file containing aerial lidar data, create a digital surface model (DSM) from the data, reference the DSM to projected coordinates, crop the DSM to an area of interest, and export the cropped DSM to a GeoTIFF file.
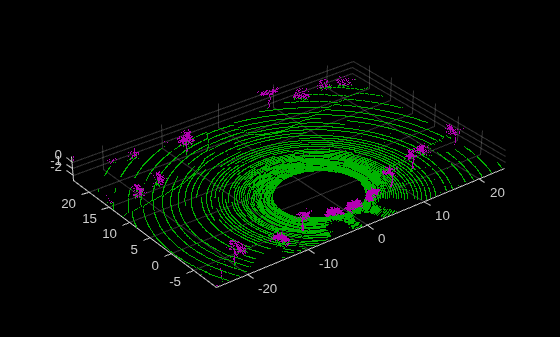
Extract On-Road and Off-Road Points from Point Cloud
Extract on-road and off-road points from point cloud data.
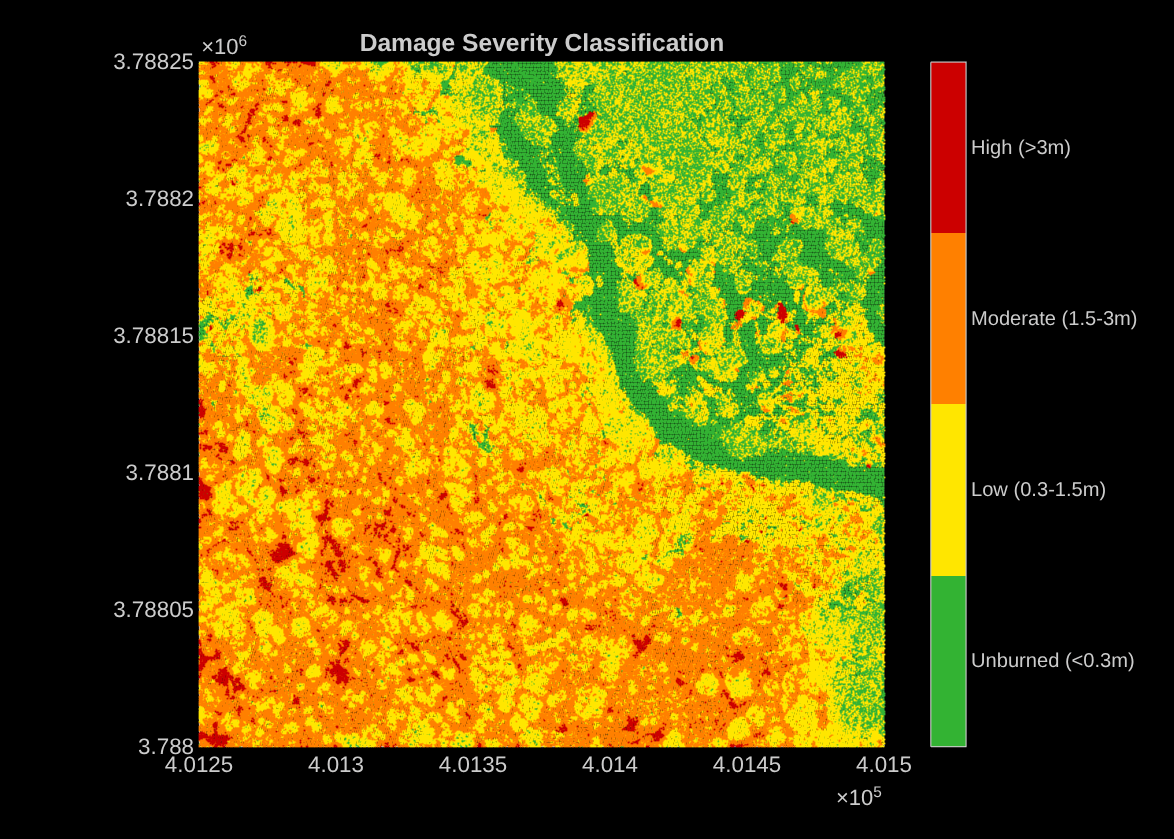
Estimate Forest Fire Canopy Damage from Aerial Lidar Point Clouds
Assess forest canopy damage after wildfire by comparing pre-fire and post-fire aerial lidar point clouds.
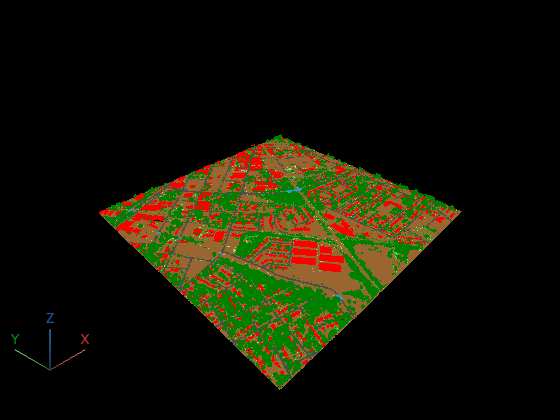
Visualize LAS Classification Labels
Read classification attributes from a LAS file and color the point cloud by class in pcviewer. Point cloud data from collection methods like aerial surveys often includes per-point classification labels (ground, vegetation, buildings) following the ASPRS standard.

