장면 작성을 위한 MATLAB 함수
R2026bMATLAB®을 사용하여 액터, 논리 단계, 웨이포인트와 같은 RoadRunner 시나리오 요소를 생성하고 수정합니다.
Automated Driving Toolbox™는 MATLAB 명령줄 인터페이스에서 도로 추가, 도로 지오메트리 수정, 차선과 분기점 추가 등 RoadRunner에서 장면을 프로그래밍 방식으로 작성할 수 있는 함수를 제공합니다. 장면을 프로그래밍 방식으로 작성하면 애플리케이션을 전환하지 않고도 장면을 신속하게 구축할 수 있으며, 반복적인 작성 작업을 자동화하고 자동화된 테스트를 위한 장면 변형을 생성할 수 있습니다.
함수
roadrunnerAPI | RoadRunner authoring API (R2025a 이후) |
Project | Specify RoadRunner project folder (R2025a 이후) |
Scene | Current RoadRunner scene (R2025a 이후) |
createAsset | Create new asset (R2025a 이후) |
getAsset | Extract object for specified asset (R2025a 이후) |
도로 유형 정의하기
addLineArcRoad | Add road with line-arc horizontal curve type to RoadRunner scene (R2025a 이후) |
addSegmentedRoad | Add road with segmented curve type to RoadRunner scene (R2025a 이후) |
addClothoidFitRoad | Add clothoid curve type road to RoadRunner scene (R2025a 이후) |
도로 레이아웃
Road | Specify road in RoadRunner scene (R2025a 이후) |
수평 도로 곡선 지오메트리 정의하기
addControlPoint | Add control point to line-arc road curve (R2025a 이후) |
addLine | Add new line segment to horizontal curve of segmented road (R2025a 이후) |
addArc | Add new arc segment to horizontal curve of segmented road (R2025a 이후) |
addSpiral | Add new spiral segment to horizontal curve of segmented road (R2025a 이후) |
addParametricCubic | Add new parametric cubic segment to horizontal curve of segmented road (R2025a 이후) |
수평 도로 곡선 유형
LineArcRoadCurve | Specify line-arc road curve in RoadRunner scene (R2025a 이후) |
LineArcRoadCurvePoint | Specify control point on line-arc road curve in RoadRunner scene (R2025a 이후) |
SegmentedRoadCurve | Define horizontal curve of segmented road (R2025a 이후) |
Lane 객체 추출하기
Lane | Lane on road in RoadRunner scene (R2025a 이후) |
ReferenceLane | Reference lane of road in RoadRunner scene (R2025a 이후) |
차선 추가하기
addLaneToRight | Add lane to right side of specified lane (R2025a 이후) |
addLaneToLeft | Add lane to left side of specified lane (R2025a 이후) |
차선 표식 프로파일 정의하기
LaneMarkingProfile | Marking profile for lane boundaries in RoadRunner scene (R2025a 이후) |
LaneMarkingStyle | Marking style of lane boundary in RoadRunner scene (R2025a 이후) |
LaneMarkingSpan | Span in lane marking profile in RoadRunner scene (R2025a 이후) |
LaneMarkingNode | Node in lane marking profile in RoadRunner scene (R2025a 이후) |
차선 너비 프로파일 정의하기
LaneWidthProfile | Width profile for lane boundaries in RoadRunner scene (R2025a 이후) |
LaneWidthSpan | Span in lane width profile in RoadRunner scene (R2025a 이후) |
LaneWidthNode | Node in lane width profile in RoadRunner scene (R2025a 이후) |
수직 도로 곡선 지오메트리 정의하기
insertNode | Insert node in span sequence (R2025a 이후) |
수직 도로 곡선 유형
SpanSequence | Define sequence of nodes connected by spans (R2025a 이후) |
SpanSequenceNode | Define span sequence node in span sequence (R2025a 이후) |
SpanSequenceSpan | Define span between two nodes in span sequence (R2025a 이후) |
SuperElevationCurve | Road superelevation or banking angle profile (R2026a 이후) |
SuperElevationNode | Road superelevation or banking angle at point (R2026a 이후) |
SuperElevationSpan | Banking angle transition between adjacent superelevation nodes along road (R2026a 이후) |
addSuperElevation | Add or update road superelevation or banking angle at point (R2026a 이후) |
LateralProfile | Lateral profile of road (R2026a 이후) |
LateralProfileNode | Node in lateral profile (R2026a 이후) |
LateralProfileSpan | Span in lateral profile in RoadRunner scene (R2026a 이후) |
CrossSectionCurve | Cross-section profile of road (R2026a 이후) |
CrossSectionSpan | Span in cross-section profile (R2026a 이후) |
CrossSectionNode | Node in cross-section profile (R2026a 이후) |
addLateralHeight | Add lateral height variation to road (R2026a 이후) |
분기점 생성 및 수정하기
Junction | Junctions in RoadRunner scene (R2026b 이후) |
addJunction | Add junction to RoadRunner scene (R2026b 이후) |
clearMarkingsInJunction | Clear lane markings in junction (R2026b 이후) |
분기점 기동 관리하기
Maneuver | Maneuver roads in junction (R2026b 이후) |
addAutomaticManeuvers | Add automatic maneuvers to junction (R2026b 이후) |
addManeuver | Add maneuver roads to junction (R2026b 이후) |
코너 지오메트리 수정하기
Corner | Corner of junction connecting edges of two adjacent approach roads (R2026b 이후) |
setRadius | Set corner radius (R2026b 이후) |
도로 중첩 관리하기
OverlapGroup | Overlap group of road (R2026b 이후) |
addOverlapGroup | Add overlap group (R2026b 이후) |
getRoadOverlaps | Returns distance ranges where two roads overlap (R2026b 이후) |
분기점 토폴로지 쿼리하기
getLanes | Query direction specific lanes on road relative to junction (R2026b 이후) |
getConnectedRoads | Query approach roads connected by corner (R2026b 이후) |
getConnectedRoadOrientations | Query orientation of connected approach roads (R2026b 이후) |
getJunctions | Returns all junctions for road (R2026b 이후) |
추천 예제
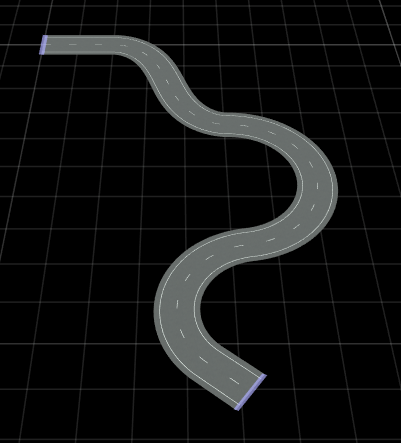
Design a Curved Road Programmatically using MATLAB Scene Authoring Functions
Design a curved road using scene authoring functions.
MATLAB Command
You clicked a link that corresponds to this MATLAB command:
Run the command by entering it in the MATLAB Command Window. Web browsers do not support MATLAB commands.


웹사이트 선택
번역된 콘텐츠를 보고 지역별 이벤트와 혜택을 살펴보려면 웹사이트를 선택하십시오. 현재 계신 지역에 따라 다음 웹사이트를 권장합니다:
또한 다음 목록에서 웹사이트를 선택하실 수도 있습니다.
사이트 성능 최적화 방법
최고의 사이트 성능을 위해 중국 사이트(중국어 또는 영어)를 선택하십시오. 현재 계신 지역에서는 다른 국가의 MathWorks 사이트 방문이 최적화되지 않았습니다.
미주
- América Latina (Español)
- Canada (English)
- United States (English)
유럽
- Belgium (English)
- Denmark (English)
- Deutschland (Deutsch)
- España (Español)
- Finland (English)
- France (Français)
- Ireland (English)
- Italia (Italiano)
- Luxembourg (English)
- Netherlands (English)
- Norway (English)
- Österreich (Deutsch)
- Portugal (English)
- Sweden (English)
- Switzerland
- United Kingdom (English)