이 페이지는 기계 번역을 사용하여 번역되었습니다. 영어 원문을 보려면 여기를 클릭하십시오.
6DOF
R2026b시뮬레이션에서 오일러 각과 쿼터니언 표현을 사용하여 6자유도 운동 방정식을 구현
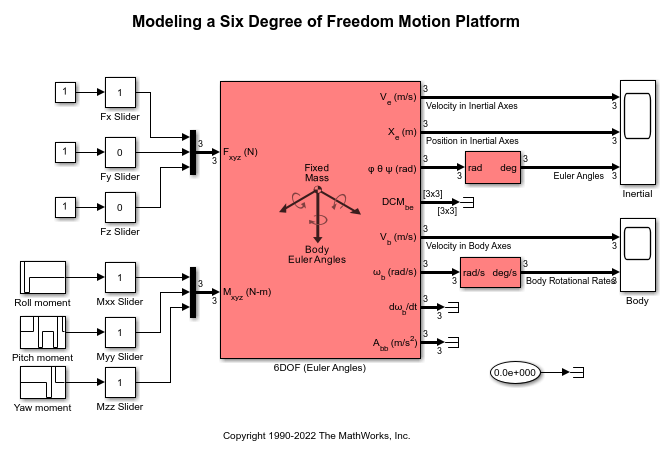
고정 또는 가변 질량 대기 비행체의 점질량 및 6자유도 동역학을 모델링하고 시뮬레이션합니다. 운동 방정식의 표현을 바디 좌표계, 풍속 좌표계 및 ECEF(지구중심고정) 좌표계에서 정의합니다. 좌표계 간 변환 및 단위 변환을 수행하여 모델의 일관성을 보장합니다.
블록
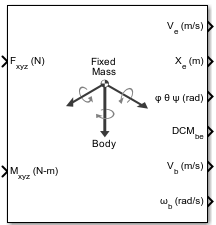 | 6DOF (Euler Angles) | 6자유도 운동 방정식의 오일러 각 표현 구현 |
 | 6DOF (Quaternion) | 바디 좌표축을 기준으로 한 6자유도 운동 방정식의 쿼터니언 표현 구현 |
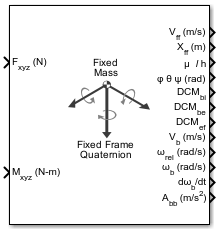 | 6DOF ECEF (Quaternion) | Implement quaternion representation of six-degrees-of-freedom equations of motion in Earth-centered Earth-fixed (ECEF) coordinates |
 | 6DOF Wind (Quaternion) | Implement quaternion representation of six-degrees-of-freedom equations of motion with respect to wind axes |
 | 6DOF Wind (Wind Angles) | Implement wind angle representation of six-degrees-of-freedom equations of motion |
 | Custom Variable Mass 6DOF (Euler Angles) | 사용자 지정 가변 질량에 대한 6자유도 운동 방정식의 오일러 각 표현 구현 |
 | Custom Variable Mass 6DOF (Quaternion) | 바디 좌표축을 기준으로 한 사용자 지정 가변 질량의 6자유도 운동 방정식을 쿼터니언으로 표현 |
 | Custom Variable Mass 6DOF ECEF (Quaternion) | Implement quaternion representation of six-degrees-of-freedom equations of motion of custom variable mass in Earth-centered Earth-fixed (ECEF) coordinates |
 | Custom Variable Mass 6DOF Wind (Quaternion) | Implement quaternion representation of six-degrees-of-freedom equations of motion of custom variable mass with respect to wind axes |
 | Custom Variable Mass 6DOF Wind (Wind Angles) | Implement wind angle representation of six-degrees-of-freedom equations of motion of custom variable mass |
 | Simple Variable Mass 6DOF (Euler Angles) | Implement Euler angle representation of six-degrees-of-freedom equations of motion of simple variable mass |
 | Simple Variable Mass 6DOF (Quaternion) | Implement quaternion representation of six-degrees-of-freedom equations of motion of simple variable mass with respect to body axes |
 | Simple Variable Mass 6DOF ECEF (Quaternion) | Implement quaternion representation of six-degrees-of-freedom equations of motion of simple variable mass in Earth-centered Earth-fixed (ECEF) coordinates |
 | Simple Variable Mass 6DOF Wind (Quaternion) | Implement quaternion representation of six-degrees-of-freedom equations of motion of simple variable mass with respect to wind axes |
 | Simple Variable Mass 6DOF Wind (Wind Angles) | Implement wind angle representation of six-degrees-of-freedom equations of motion of simple variable mass |