3DOF (Wind Axes)
R2026bImplement three-degrees-of-freedom equations of motion with respect to wind axes
3DOF (Wind Axes) block
To add a block to a model, double-click the canvas and start typing the block name. Then, select the block from the list.
Libraries:
Aerospace Blockset /
Equations of Motion /
3DOF
Description
The 3DOF (Wind Axes) block implements three-degrees-of-freedom equations of motion with respect to wind axes. It considers the rotation in the vertical plane of a wind-fixed coordinate frame about a flat Earth reference frame. For more information about the rotation and equations of motion, see Algorithms.
Limitations
The block assumes that the applied forces act at the center of gravity of the body, and that the mass and inertia are constant.
Ports
Input
Output
Parameters
Programmatic Use: Add Block
To add the block programmatically, use the add_block function with one of these library block paths as the source.
"aerolib3dof2/3dof (Wind Axes)"
Example: add_block("aerolib3dof2/3dof (Wind Axes)","myModel/myBlock",MakeNameUnique="on")
Algorithms
The block considers the rotation in the vertical plane of a wind-fixed coordinate frame about a flat Earth reference frame.
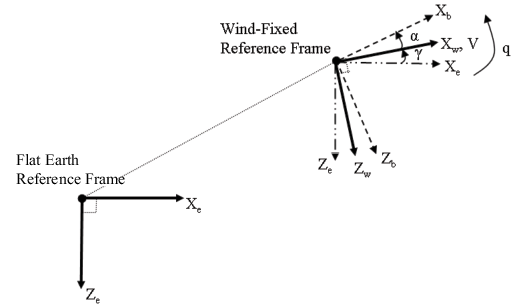
The equations of motion are
where the applied forces are assumed to act at the center of gravity of the body. Input variables are wind-axes forces Fx and Fz and body moment My. g is an optional input variable.
References
[1] Stevens, Brian, and Frank Lewis. Aircraft Control and Simulation. New York: John Wiley & Sons, 1992.

